DATASHEET

ACTILINK-JD DUO

TWO-STAGE HIGH-TORQUE ACTUATORS FOR HUMANOID AND QUADRUPED ROBOTS

High-torque motor, low-backlash two-stage planetary gearbox, and integrated SOMANET™ Circulo 9 drive in a compact housing with a hollow shaft. For joints that require high output torque and rigidity.

TECHNICAL DATA
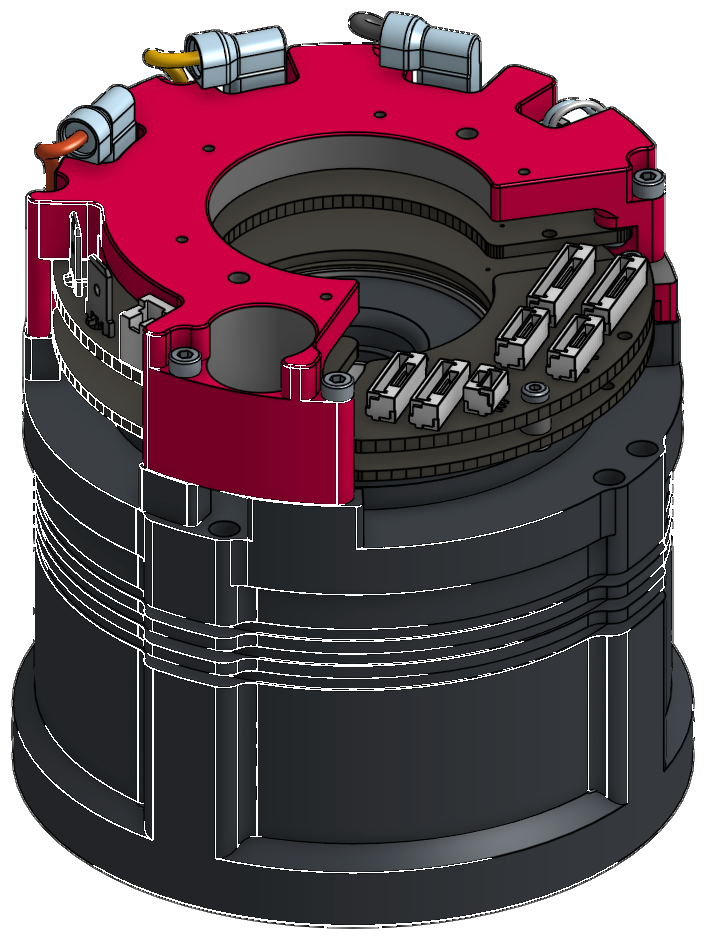
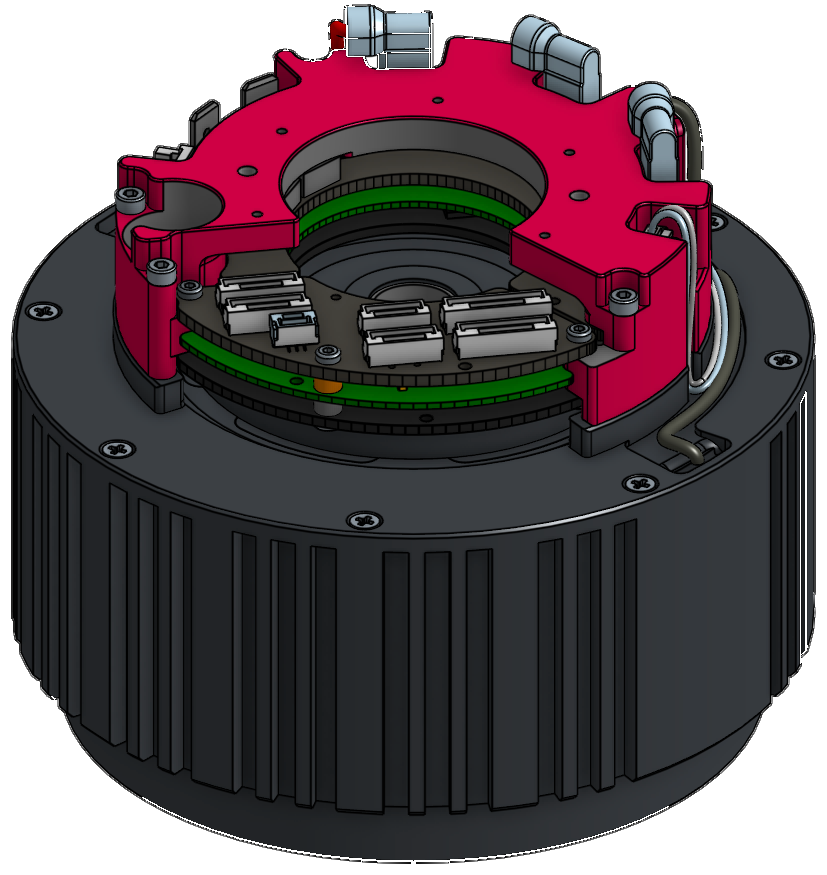
ACTILINK-JD10 DUO ActuatorACTILINK-JD12 DUO Actuator

AT A GLANCE

The ACTILINK-JD DUO series combines a high-torque motor with a low-backlash two-stage planetary gearbox and an integrated SOMANET™ Circulo 9 drive. The result is high torque density in a compact housing with a hollow shaft, designed for humanoid and quadruped robots where output torque and stiffness are critical.

Two-stage planetary gearbox: high torque density with backlash of less than 10 arcmin.

Hollow shaft, Ø 12.6 mm: for cable routing, with an integrated cross-roller bearing on the output end.

SOMANET™ Software: easy to use, EtherCAT, powerful motion control.

Functional Safety: STO and SBC included as standard; Safe Motion via FSoE available as an option.

2

MODEL SIZES: JD10 DUO AND JD12 DUO

215 Nm

MAX. ACCELERATION TORQUE (JD12 DUO)

86.5 Nm/kg

TORQUE-RESISTANT TIP (JD12 DUO)

< 10 arcmin

GEAR RATIO

COMPARISON OF TECHNICAL SPECIFICATIONS

Performance data at a 48 V supply voltage.

FEATURE
ACTILINK-JD10 DUO
ACTILINK-JD12 DUO
Product Variant
AJB-10-120-150
AJB-12-200-120
Supply Voltage
24 to 48 V, 48 V nominal, 60 V peak
Peak torque density
77.8 Nm/kg
86.5 Nm/kg
Rated Output Power
477 W
628 W
Max. Acceleration Torque
120 Nm
215 Nm
Rated torque ‡
43 Nm
95 Nm
Idle speed
170 rpm
120 rpm
Rated speed
120 rpm
100 rpm
Outer diameter
96 mm
124 mm
Length
101.3 mm
102.2 mm
Weight *
1,542 g
2,485 g
Hollow shaft
Ø 12.6 mm
Ø 12.6 mm
Transmission
Two-stage planetary gearset
Translation
19.612 : 1
20 : 1
Integrated Drive
SOMANET Circulo 9
SOMANET Circulo 9
Motor Encoder
20-bit absolute
20-bit absolute
Output encoder
20-bit absolute, battery-powered multiturn (Variant D1)
Communication
EtherCAT (DS402)
EtherCAT (DS402)
Security Features
STO-SBC / Safe Motion (FSoE)

* Weight for the ECD1SS model. The ECD1SM (Safe Motion) weighs about 25 g more. The outer diameter and length are the same for all ECD1 models.
‡ The rated torque depends on the speed. The value listed is for the lowest rated speed; all speed-torque points can be found for the respective variant.

AJB-10-120-150
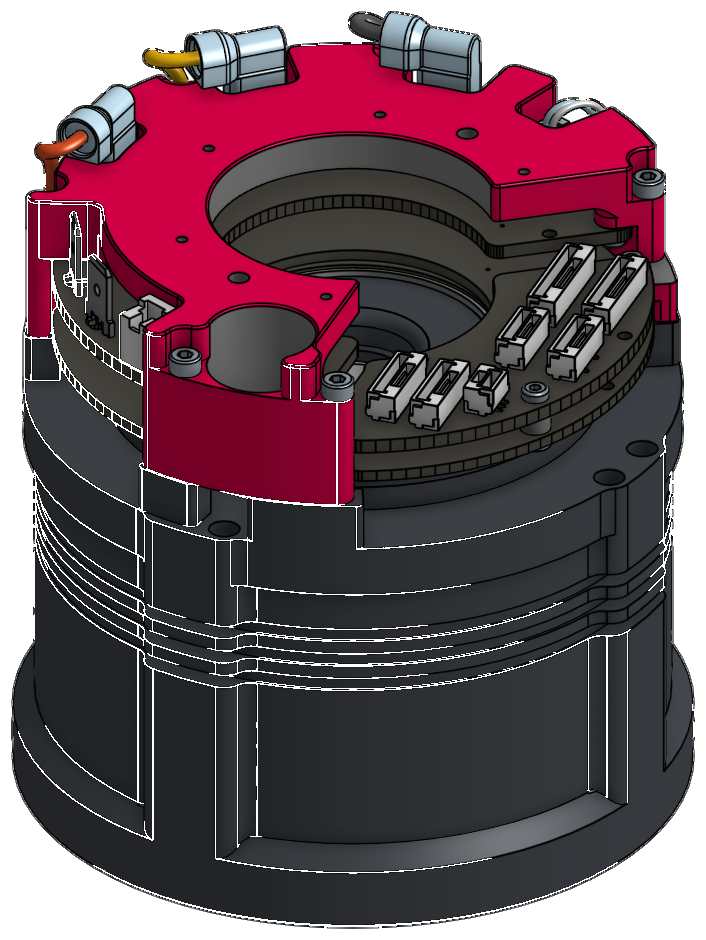
ACTILINK-JD10 DUO

ACTILINK-JD10 DUO Actuator with Integrated SOMANET Circulo 9
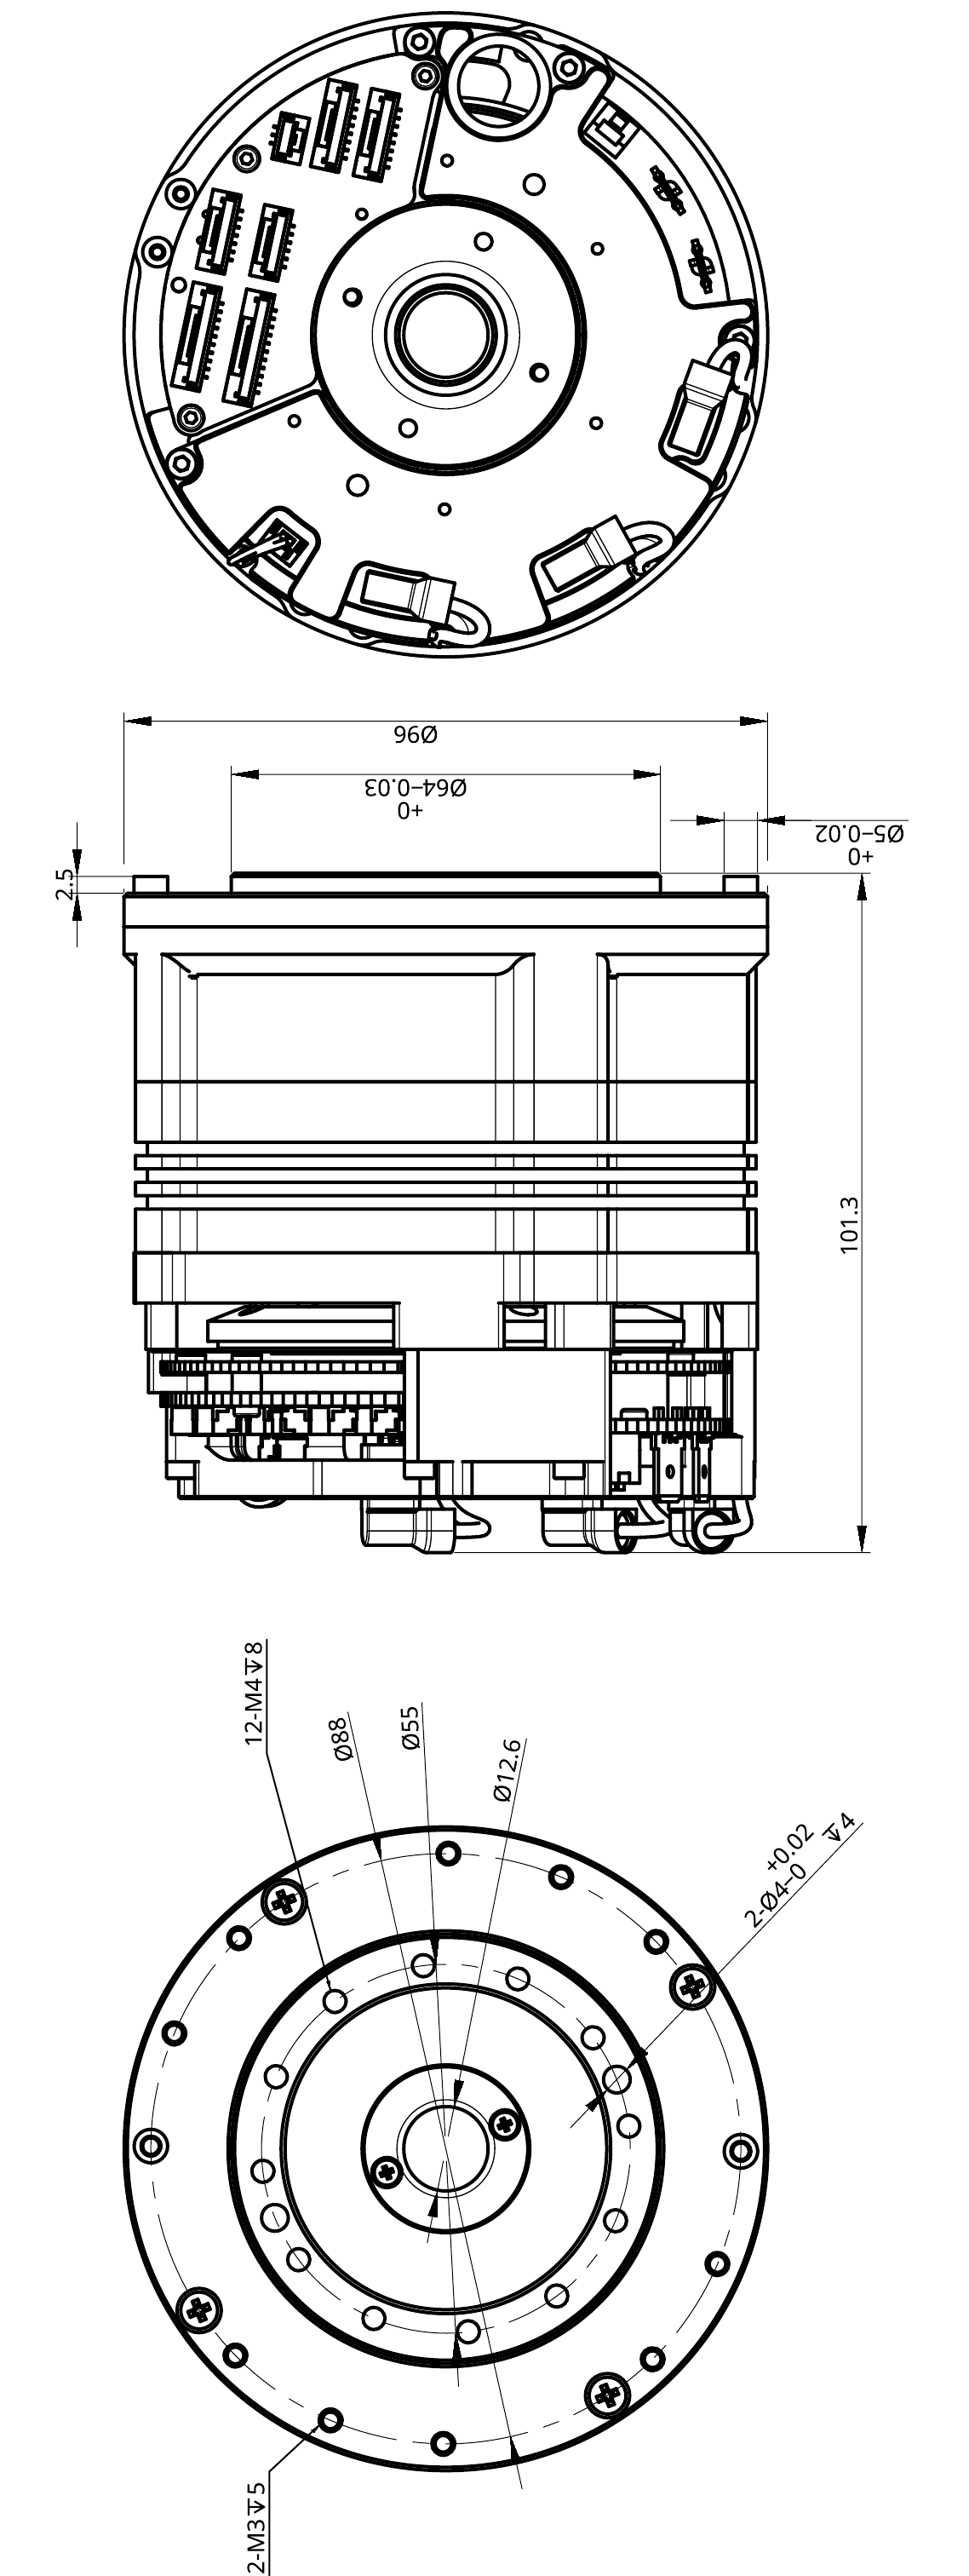
Dimensional Drawing ACTILINK-JD10 DUO

Dimensional Drawing ECD1: Dual Encoder (Motor and Output Shaft), Hollow Shaft. All dimensions in mm.

POWER AT 48 V
Rated torque
38 Nm at 120 rpm
, 43 Nm at 60 rpm
Max. Acceleration Torque
120 Nm
Rated Output Power
477 W
Peak torque density
77.8 Nm/kg
Idle speed
170 rpm
Rated speed
120 rpm
DRIVE BEARING
Dynamic load capacity
5,680 N
Static Load Capacity
8,680 N
Rolling Circle Diameter Ø
67 mm
Center of the bearing to the output shaft
9.5 mm
Rated service life
1,000,000 revolutions
MECHANICS
Weight †
1,542 g
Outer diameter
96 mm
Length *
101.3 mm
Hollow Shaft Diameter
Ø 12.6 mm
Inertia (based on the transmission)
0.07 kg·m²
Transmission
Two-stage planetary gearset
Translation
19.612 : 1
Gearplay
< 10 arcmin
POWER TRAIN AND ELECTRONICS
Motor
20 pairs of poles (40 poles)
Torque constant
131.1 mNm/arm
Phase resistance
70 mΩ
Phase inductance
93 µH at 1 kHz
Integrated Drive
SOMANET Circulo 9 (CR9-48-60)
Supply Voltage
24 to 48 V, 60 V peak
FEEDBACK AND SECURITY
Motor Encoder
20-bit absolute
Output encoder
20-bit absolute, battery-powered multiturn (Variant D1)
Communication
EtherCAT (DS402)
Security Features
STO-SBC / Safe Motion (FSoE)
STANDARD CONFIGURATIONS
AJB-10…ECD1SS
Dual Encoder, STO-SBC
AJB-10…ECD1SM
Dual Encoder, Safe Motion
SURROUNDINGS
Operating temperature
0 to 50 °C (ambient air)
Storage Temperature
-30 to 70 °C

† ECD1SS model. The ECD1SM weighs 1,567 g.
* Length includes standard connectors. Custom connectors reduce the length by up to 7 mm.

AJB-12-200-120
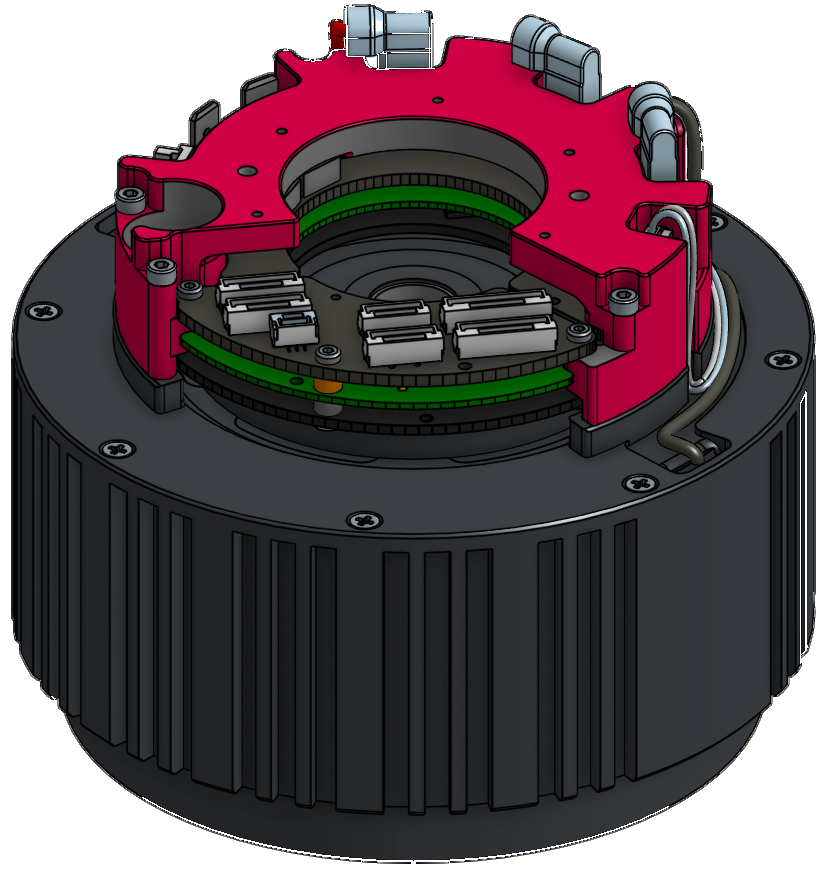
ACTILINK-JD12 DUO

ACTILINK-JD12 DUO Actuator with Integrated SOMANET Circulo 9
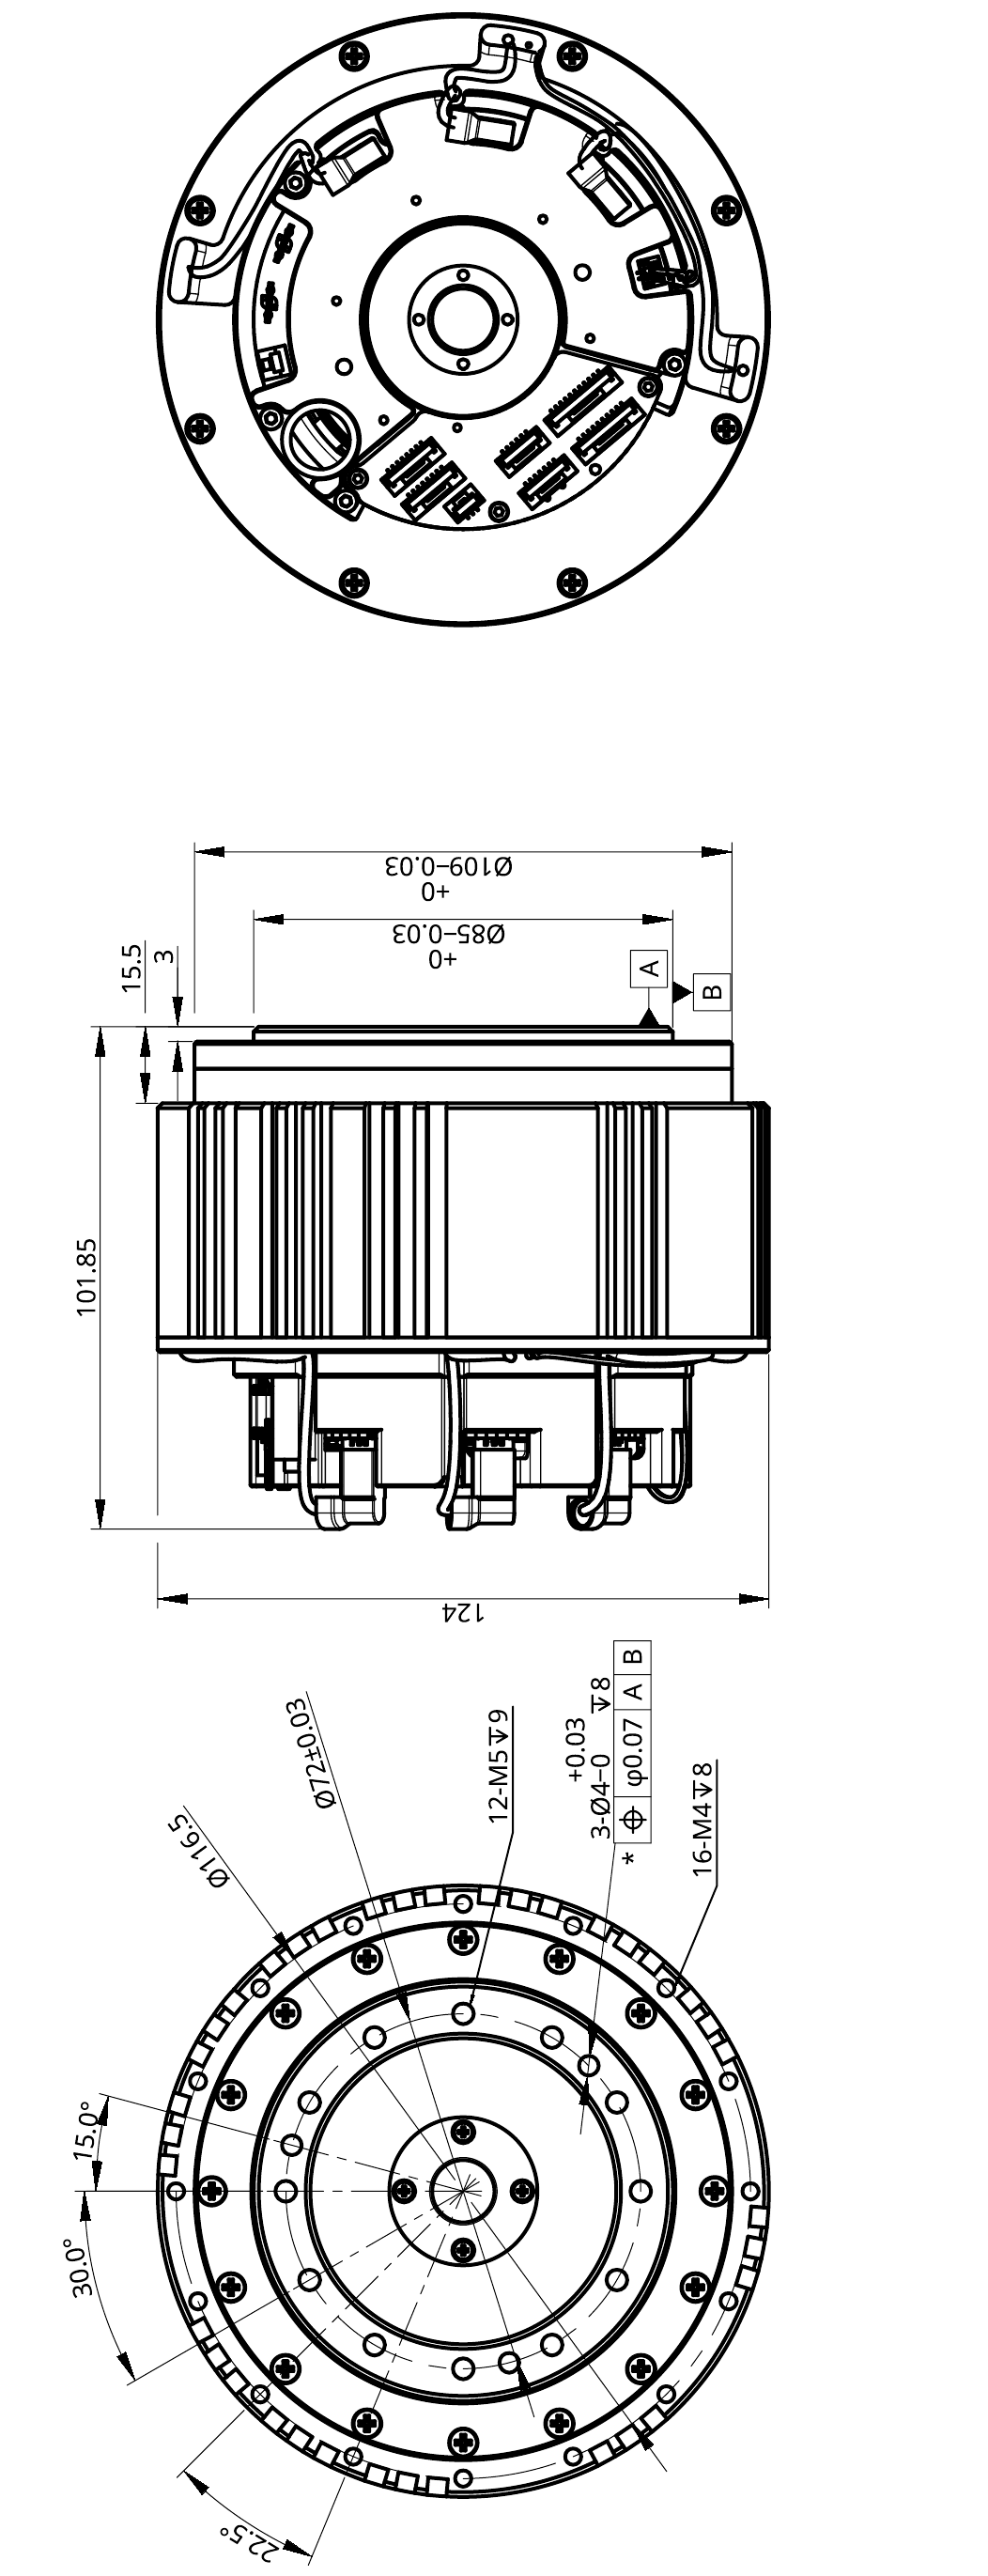
Dimensional Drawing ACTILINK-JD12 DUO

Dimensional Drawing ECD1: Dual Encoder (Motor and Output Shaft), Hollow Shaft. All dimensions in mm.

POWER AT 48 V
Rated torque
60 Nm at 100 rpm
75 Nm at 30 rpm
95 Nm at 10 rpm
Max. Acceleration Torque
215 Nm
Rated Output Power
628 W
Peak torque density
86.5 Nm/kg
Idle speed
120 rpm
Rated speed
100 rpm
DRIVE BEARING
Dynamic load capacity
6,370 N
Static Load Capacity
11,300 N
Rolling Circle Diameter Ø
87 mm
Center of the bearing to the output shaft
10 mm
Rated service life
1,000,000 revolutions
MECHANICS
Weight †
2,485 g
Outer diameter
124 mm
Length *
102.2 mm
Hollow Shaft Diameter
Ø 12.6 mm
Inertia (based on the transmission)
0.33 kg·m²
Transmission
Two-stage planetary gearset
Translation
20 : 1
Gearplay
< 10 arcmin
POWER TRAIN AND ELECTRONICS
Motor
20 pairs of poles (40 poles)
Torque constant
206.7 mNm/arm
Phase resistance
43 mΩ
Phase inductance
25 µH at 1 kHz
Integrated Drive
SOMANET Circulo 9 (CR9-48-60)
Supply Voltage
24 to 48 V, 60 V peak
FEEDBACK AND SECURITY
Motor Encoder
20-bit absolute
Output encoder
20-bit absolute, battery-powered multiturn (Variant D1)
Communication
EtherCAT (DS402)
Security Features
STO-SBC / Safe Motion (FSoE)
STANDARD CONFIGURATIONS
AJB-12…ECD1SS
Dual Encoder, STO-SBC
AJB-12…ECD1SM
Dual Encoder, Safe Motion
SURROUNDINGS
Operating temperature
0 to 50 °C (ambient air)
Storage Temperature
-30 to 70 °C

† ECD1SS model. The ECD1SM weighs 2,510 g.
* Length includes standard connectors. Custom connectors reduce the length by up to 7 mm.

TYPE CODE

The manufacturer's part number (MPN) uniquely identifies each model. Example: AJB-12-200-120-ECD1SMN-00

PRODUCT FAMILY

AJB

Actilink Joint Dynamic Duo

OUTER DIAMETER, TORQUE, AND SPEED CLASS

12-200-120

10-120-150: approx. 100 mm, 120 Nm, 150 rpm
12-200-120: approx. 120 mm, 200 Nm, 120 rpm

FIELD BUS

EC

EC: EtherCAT

FEEDBACK ENCODER

D1

D1: Dual, motor and output, internal
D3: other combinations

SAFETY

SM

SS: STO / SBC via IO
SM: Safe Motion via FSoE

BRAKE

N

N: No brake
S: Spring-actuated friction brake
P: Permanent magnet friction brake
M: Synapticon Microcoil

VERSION

00

00: Standard Version

CUSTOMER-SPECIFIC

XXXX

blank: Default

Custom configurations, delivery times, and minimum order quantities are available upon request.

CUSTOMER-SPECIFIC OPTIONS

Beyond the mechanics, Synapticon provides drives, control systems, and sensors—all the way through to full-body safety: concepts, designs, feasibility studies, and integration across the entire robot system.

Brake: Friction brake or Synapticon Microcoil

Mechanical Design and Interfaces Suitable for Integration

Engine and Transmission Selection (Gear Ratio, Torque, and RPM Range)

Additional Sensors: Torque Measurement, IMU

Design of Bearing and Load-Bearing Structures

Balancing Thermal Performance, Emergency Stop, and Service Life

Upon request; NRE costs may apply. Subject to technical changes.