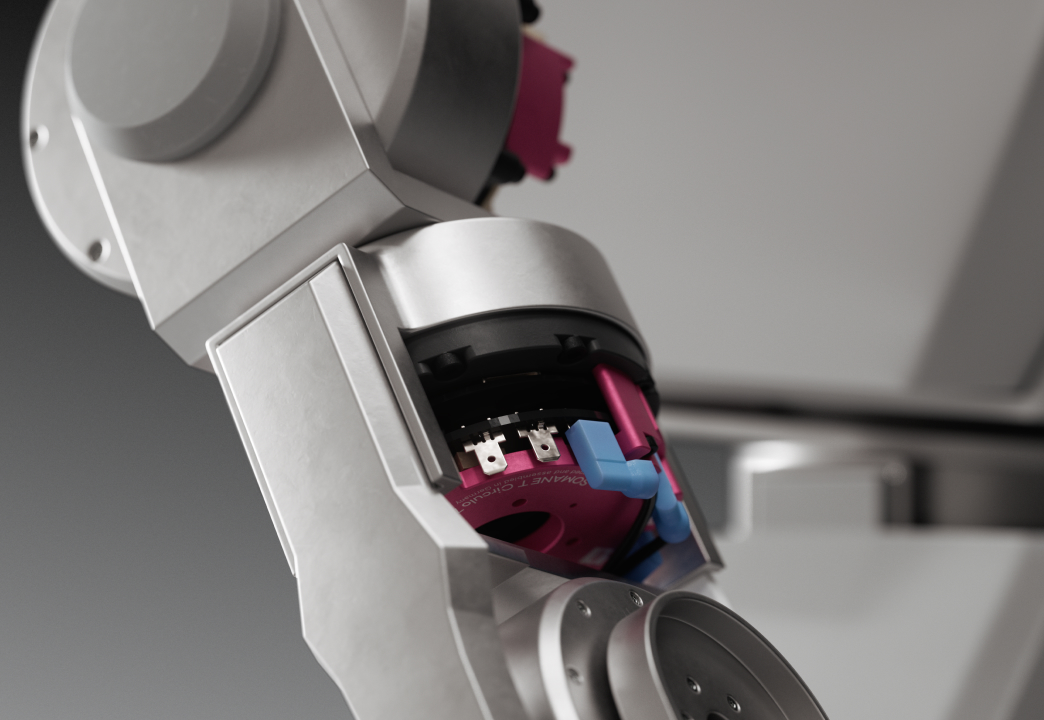
Precision at the Joint Level
Extremely low gear backlash and precise position control along the critical paths of the arm, leg, and torso joints.

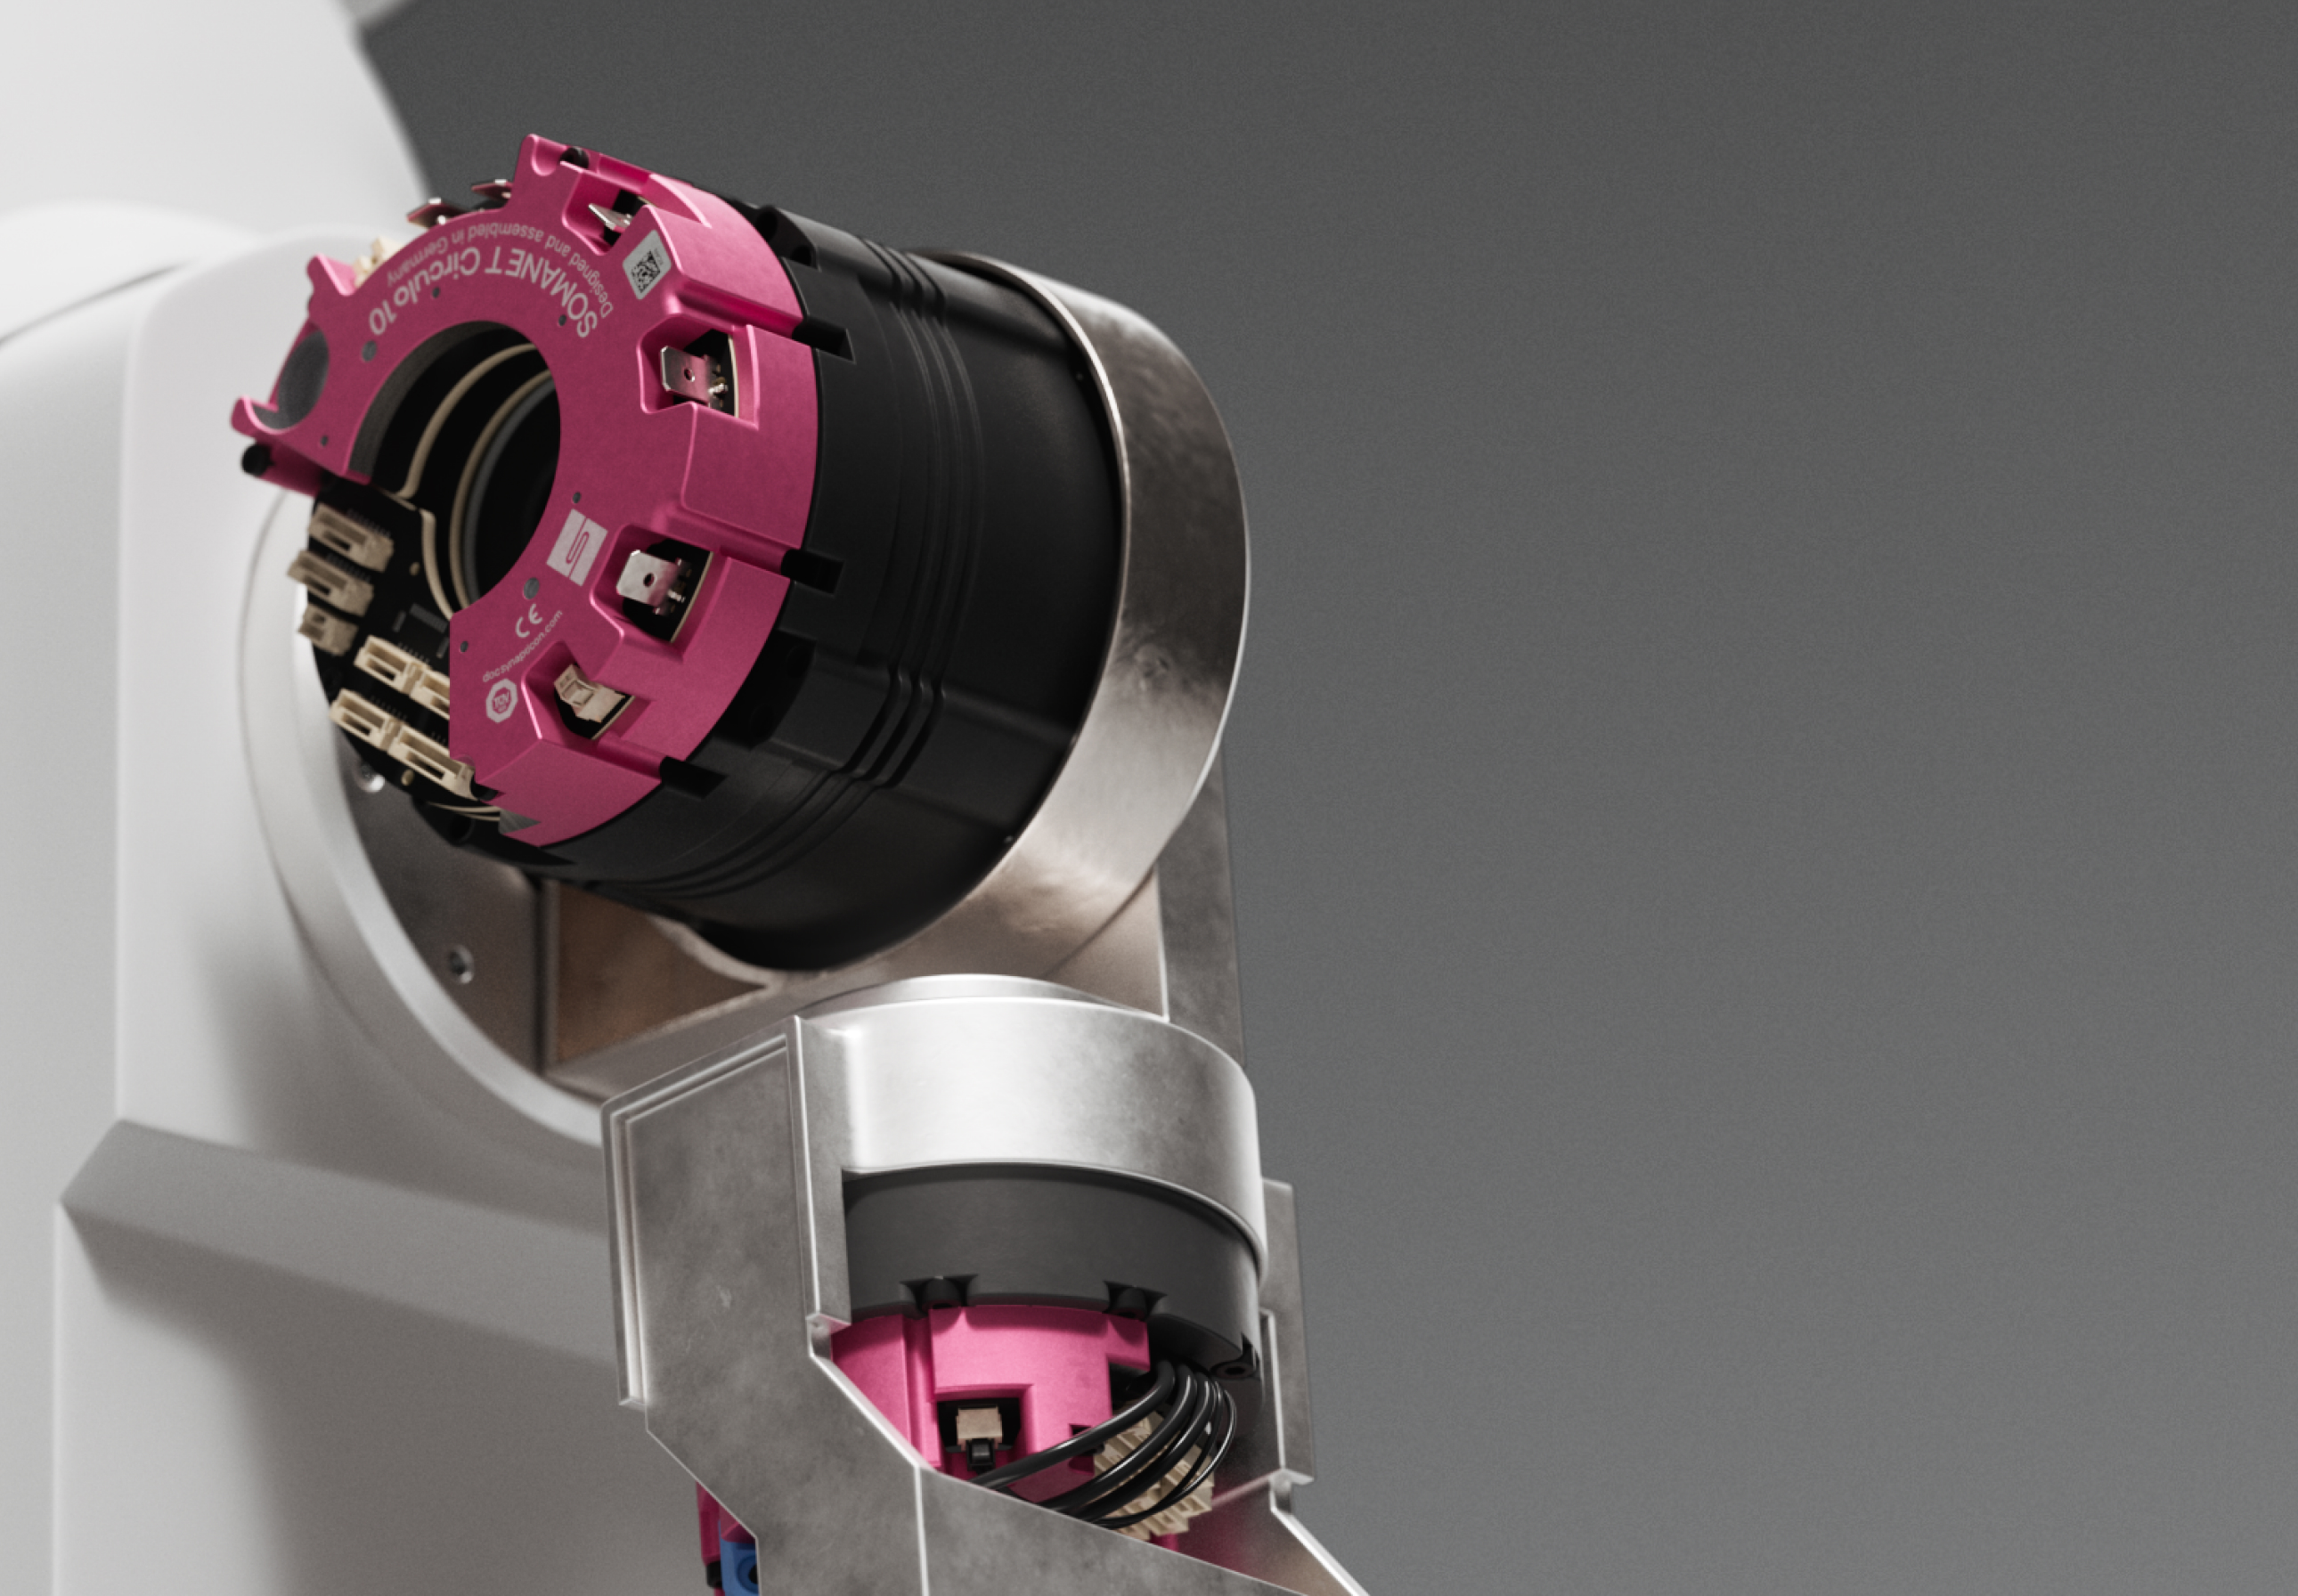
High torque density and precise motion control for modular robotics
A compact design that combines high torque density, precise performance, and flexibility for humanoid robotics.
Download the data sheets for ACTILINK-JD 8-12 and ACTILINK-JD DUO, which include all technical specifications.
This is not spam. We use your information solely to respond to your inquiry.
The ACTILINK-JD Series actuators are ideal for dynamic applications where precise motion control and reliability are critical.
Extremely low gear backlash and precise position control along the critical paths of the arm, leg, and torso joints.
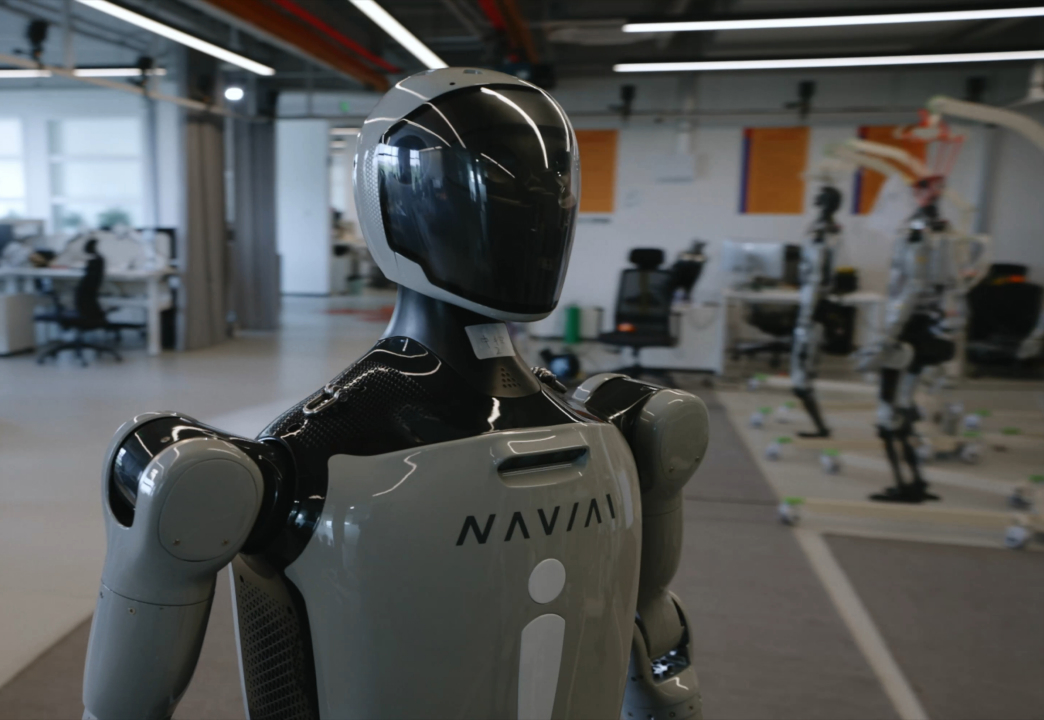
The high torque density ensures agility when walking, running, and performing complex balancing tasks for bipedal robots.
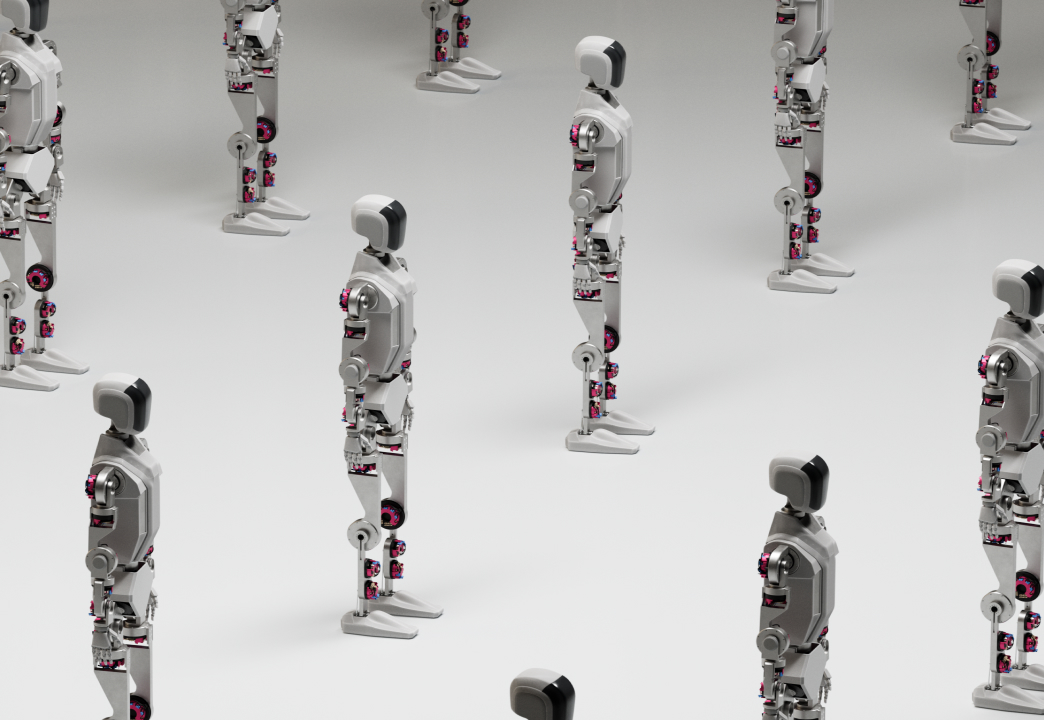
Compact, lightweight design with scalable performance for humanoid platforms of various sizes.
Integrated into leg, torso, and arm joints, with a peak torque density of up to 64.8 Nm/kg and real-time EtherCAT synchronization for dynamic bipedal walking and balance control.
Built directly into the hip and knee joints. The motor, drive, and encoder are housed in a very small space, which reduces the inertia of the limbs and minimizes internal wiring.
Used in hip and knee assistance modules. Extremely low gear backlash and safety functions, certified to SIL3 / PLe (Cat. 3), ensure smooth, biomechanically natural force feedback.
Developed and tested for outstanding performance. This is made possible by a sophisticated design featuring high power transmission and minimal gear backlash, combined with a highly dynamic motor and a servo drive that offers high power density, low energy consumption, and a very compact footprint.
The system was developed for humanoid robot architectures and makes it easier to scale systems or adapt them to new bipedal applications. This is particularly helpful for engineering teams whose kinematic requirements change frequently.
ACTILINK-JD lowers maintenance costs and reduces cabling. High efficiency in demanding applications, at a price designed for scalability.
Request PricesThe ACTILINK-JD 8-12 features a single-stage planetary gearbox, standardized EtherCAT DS402 communication, and robust safety functions, including STO-SBC and Safe Motion via FSoE (SIL3, PLe, Cat. 3).
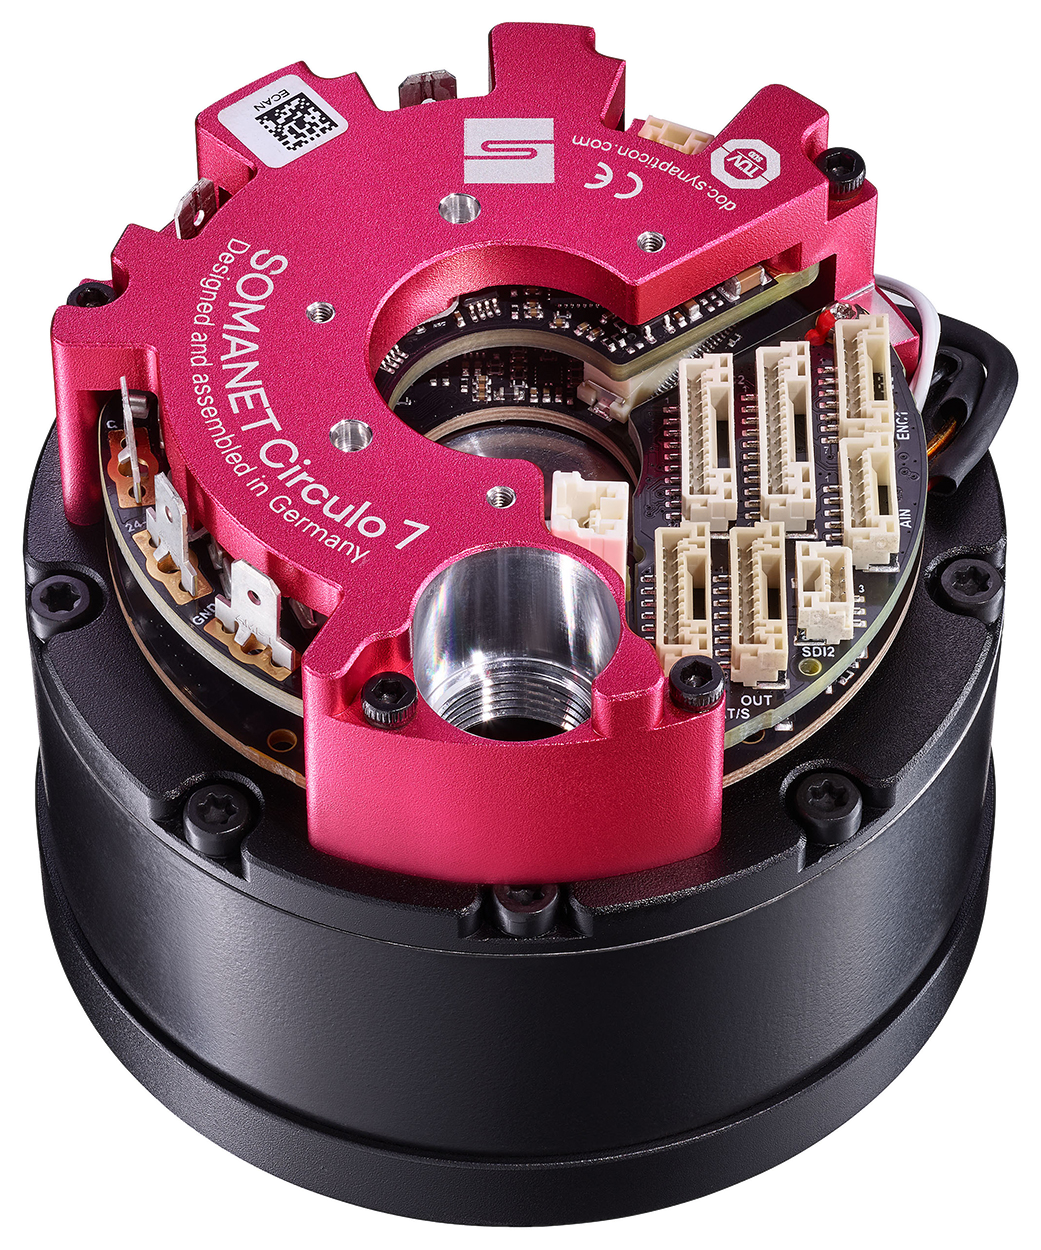 |  | 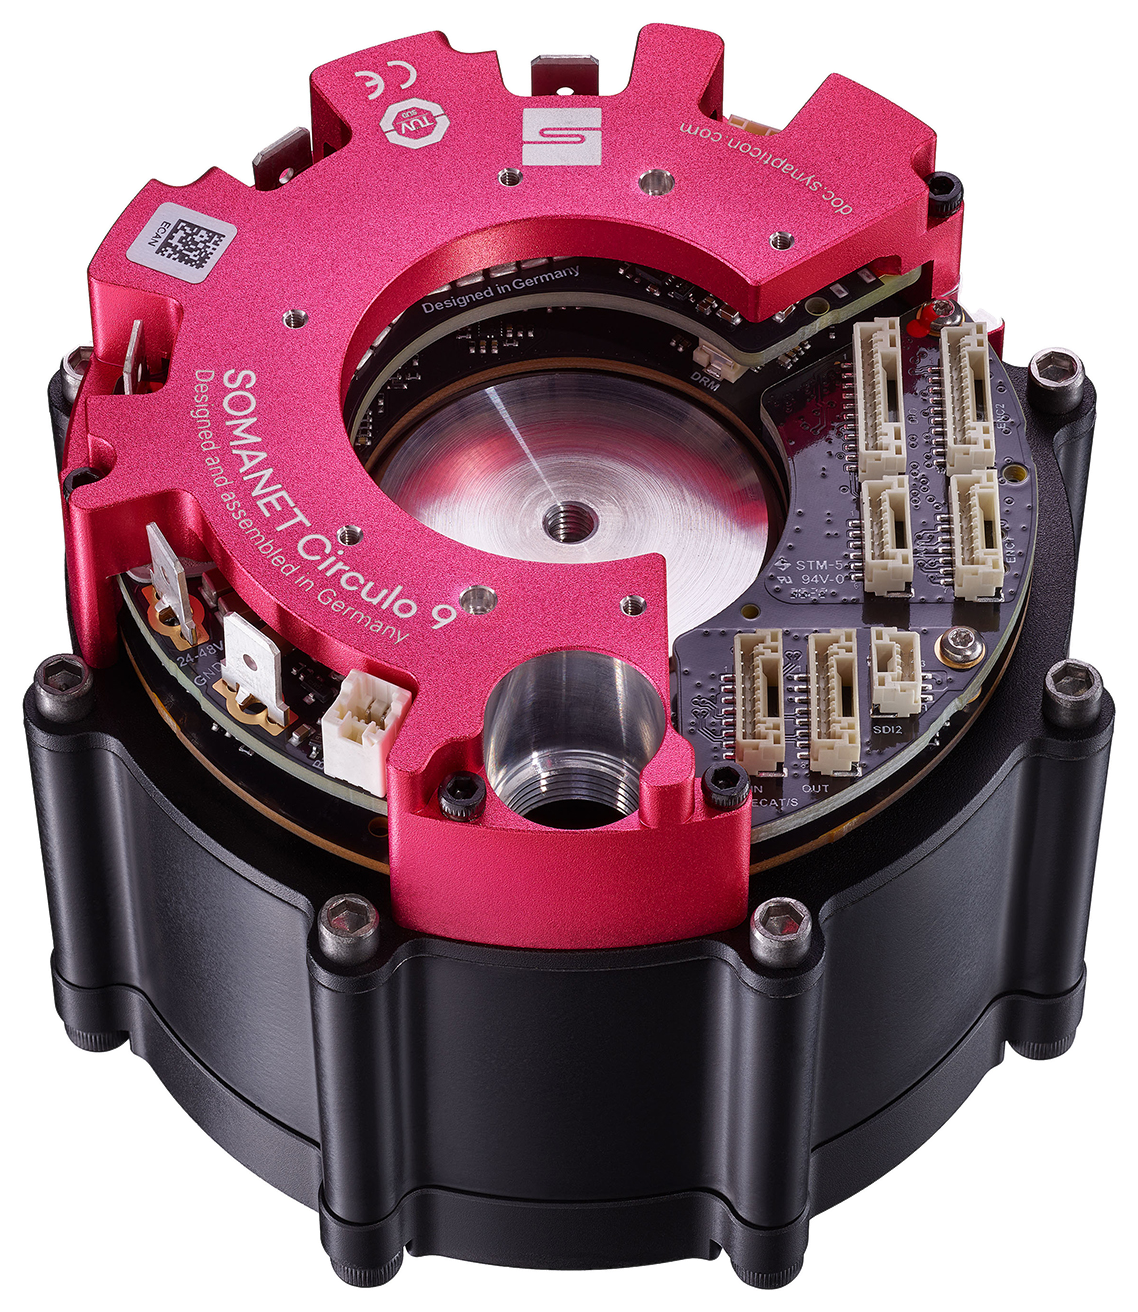 | 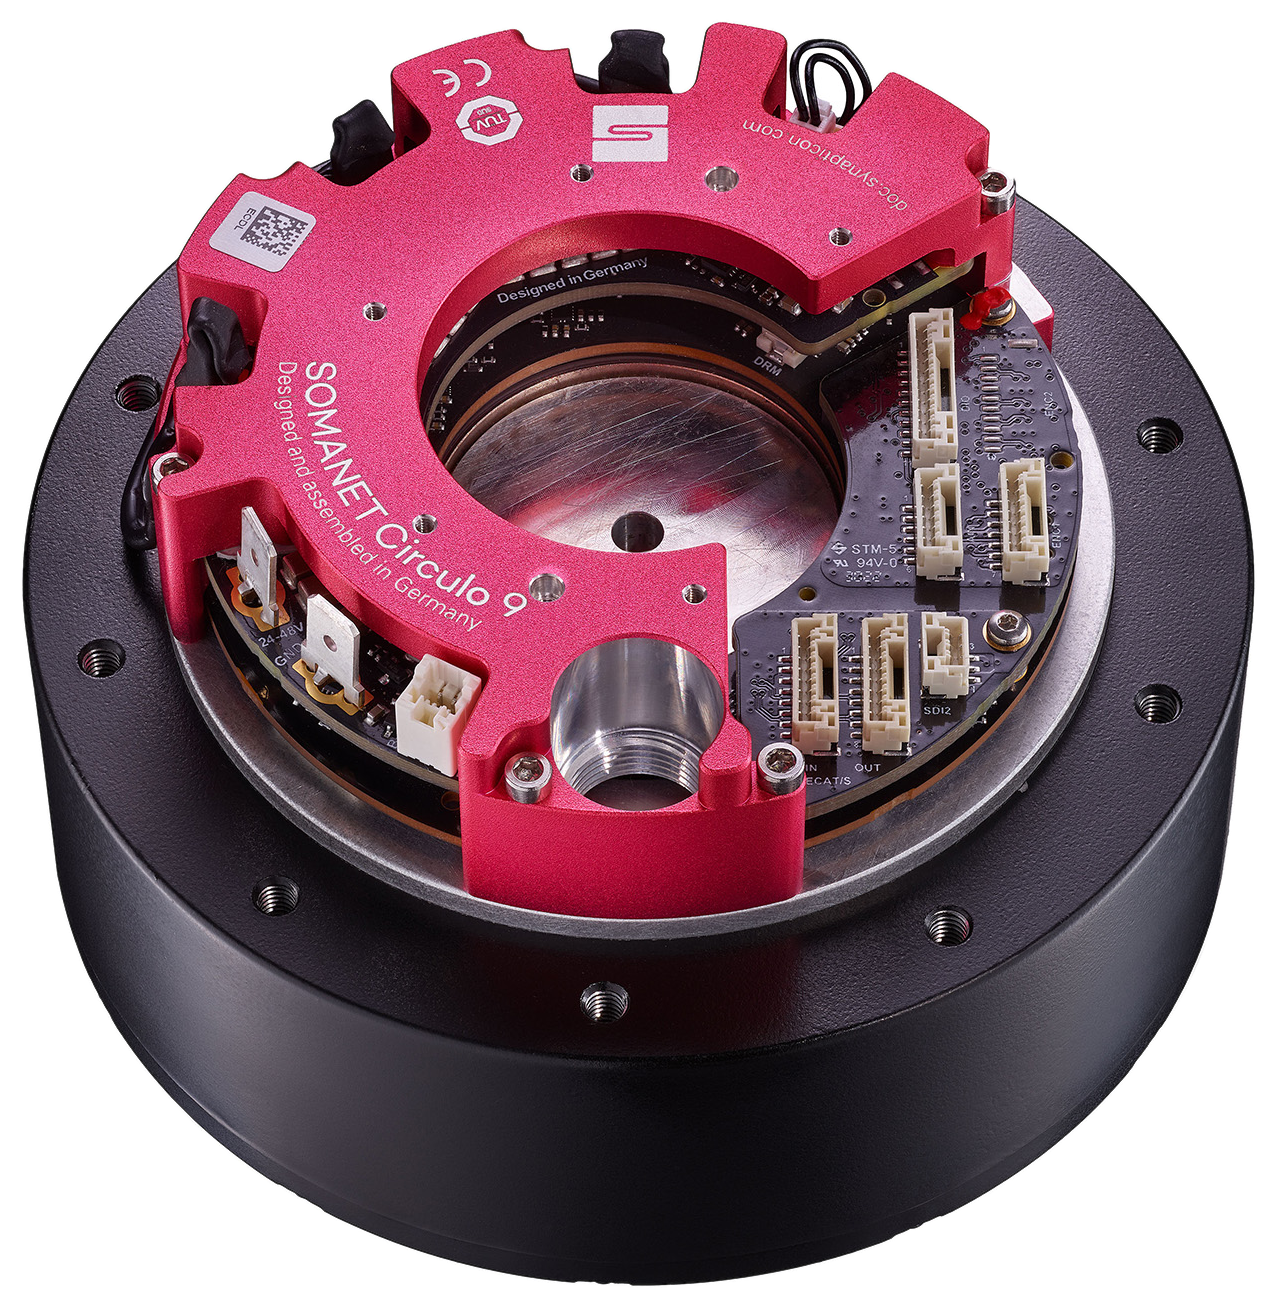 | |
| Specifications | ACTILINK-JD 8 | ACTILINK-JD 9 | ACTILINK-JD 10 | ACTILINK-JD 12 |
|---|---|---|---|---|
| Continuous torque (Nm) | 7 | 11 | 21 | 29 |
| Max. Acceleration Torque (Nm) | 17 | 30 | 68 | 102 |
| Peak Power (W) | 397 | 696 | 624 | 1036 |
| Peak torque density (Nm/kg) | 33.3 | 38.0 | 64.8 | 64.6 |
| Idle speed (rpm) | 400 | 470 | 210 | 200 |
| Weight (g) | 510–640 | 680–810 | 1050–1255 | 1580–1870 |
| Outer Diameter (mm) | 78.5–80 | 88 | 106 | 120 |
| Length (mm) | 65.5–73 | 70.29 - 79.29 | 72.8–86.3 | 72.8–85.5 |
| Reduction ratio | 7.75 | 9 | 9 | 9 |
| Gearbacklash (minutes of arc) | < 22 | < 15 | < 13 | < 11 |
| Motor Encoder | 19 bits absolute | 19 bits absolute | 20 bits absolute | 20 bits absolute |
| Output Encoder | 20 bits absolute | 20 bits absolute | 20 bits absolute | 20 bits absolute |
Up to 215 Nm of maximum acceleration torque and a 12.6-mm hollow shaft for cable routing. For joints where torque and stiffness are critical, such as the hips and knees of humanoid robots or the legs of robotic dogs.
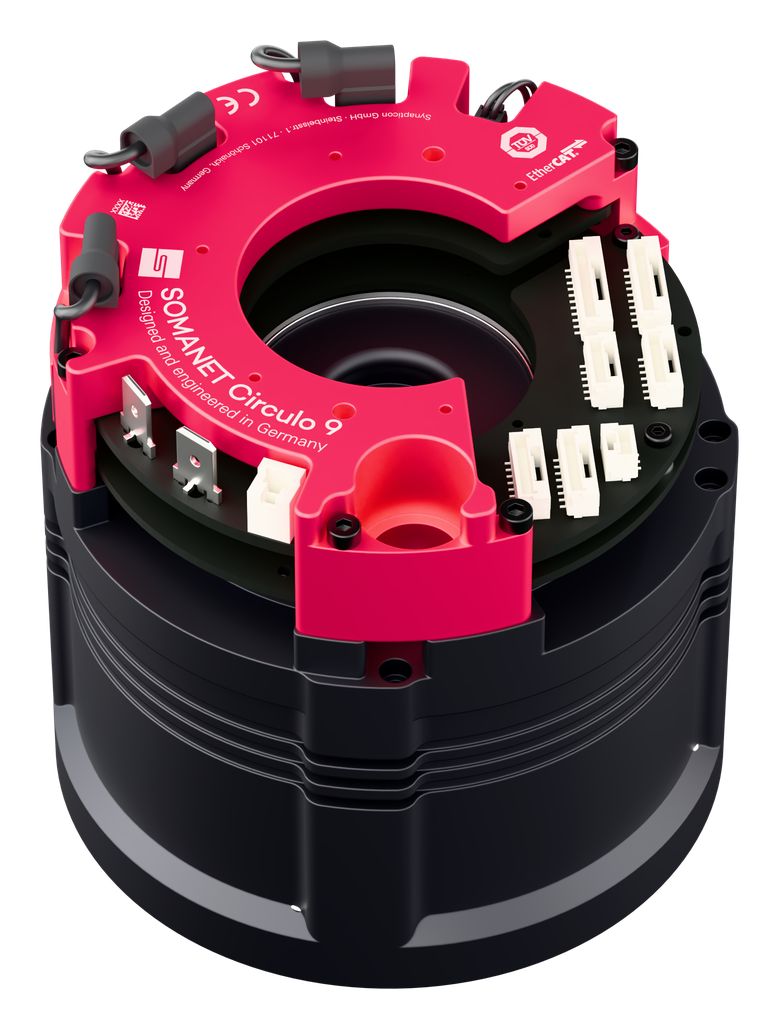 | 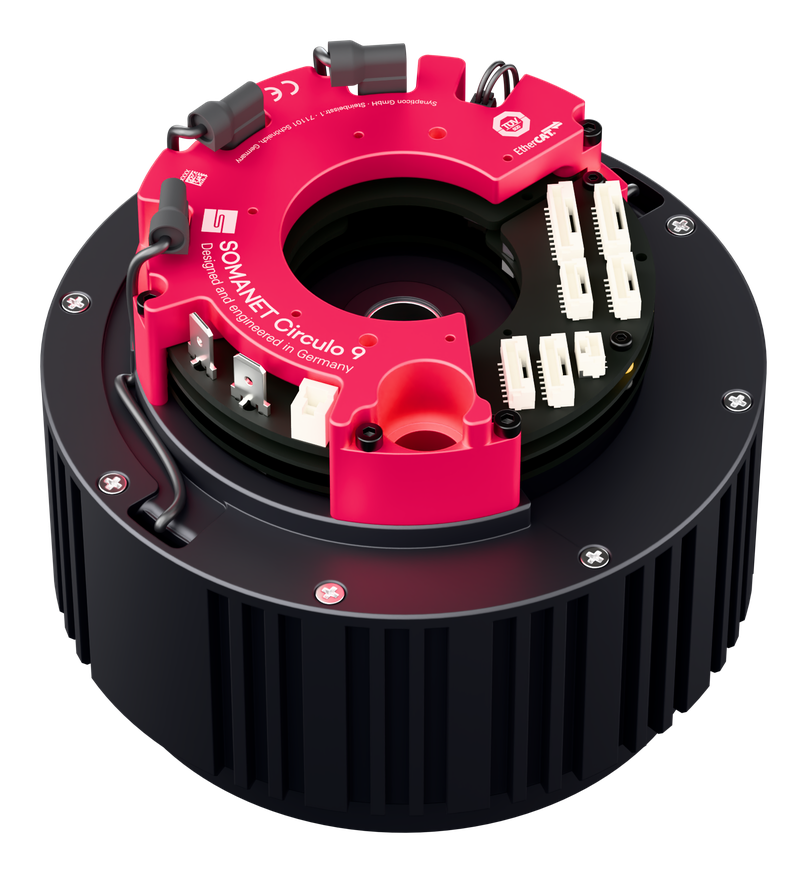 | |
| Specifications | ACTILINK-JD 10 DUO | ACTILINK-JD 12 DUO |
|---|---|---|
| Product Variant | AJB-10-120-150 | AJB-12-200-120 |
| Rated torque (Nm) | 43 | 95 |
| Max. Acceleration Torque (Nm) | 120 | 215 |
| Rated Power (W) | 477 | 628 |
| Peak torque density (Nm/kg) | 77.8 | 86.5 |
| Idle speed (rpm) | 170 | 120 |
| Outer Diameter (mm) | 96 | 124 |
| Length (mm) | 101.3 | 102.2 |
| Weight (g) | 1542 | 2485 |
| Reduction ratio | 19,612 : 1 | 20 : 1 |
| Integrated Drive | SOMANET™ Circulo 9 | SOMANET™ Circulo 9 |
| Security Features | STO-SBC / Safe Motion (FSoE) | STO-SBC / Safe Motion (FSoE) |
All technical specifications at a glance: the data sheets for ACTILINK-JD and ACTILINK-JD DUO are available as PDF files or directly online.
ACTILINK-JD 8 / 9 / 10 / 12
ACTILINK-JD 10 / 12 DUO
Want to test the integration directly in your own CAD system? The complete 3D models are available in STEP, Parasolid, or IGES formats, and in URDF format for simulation.
Download CAD ModelsWe’d be happy to advise you on our products and on the use of integrated drive technology in your application. Talk to us about your project, no matter what stage of development it’s in.
Request Expert Advice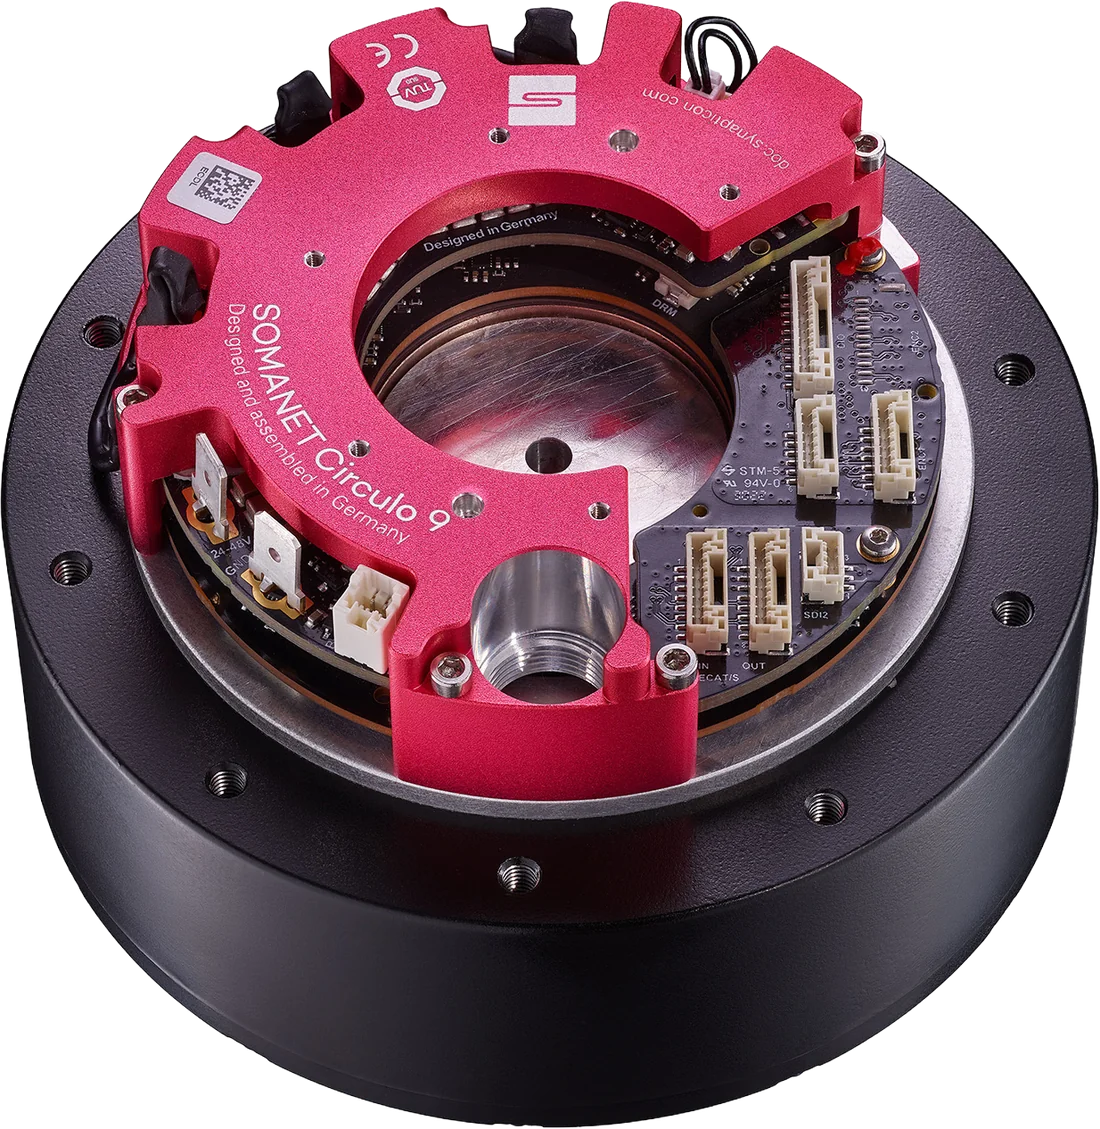
Tell us about your humanoid platform, and we'll provide you with a quote tailored to your production volumes and scaling plans.
This is not spam. We use your information solely to respond to your inquiry.
