en

N°1
INTEGRATED
MOTION
MOTION
DATASHEET
DYNAMIC ACTUATORS WITH SINGLE-STAGE PLANETARY GEARBOXES FOR HUMANOID AND QUADRUPED ROBOTS
Quasi-direct drive with a single-stage planetary gearbox, high-torque motor, and integrated SOMANET™ Circulo drive. Four sizes ranging from 78.5 to 120 mm outer diameter, with EtherCAT and Safe Motion via FSoE.
TECHNICAL DATA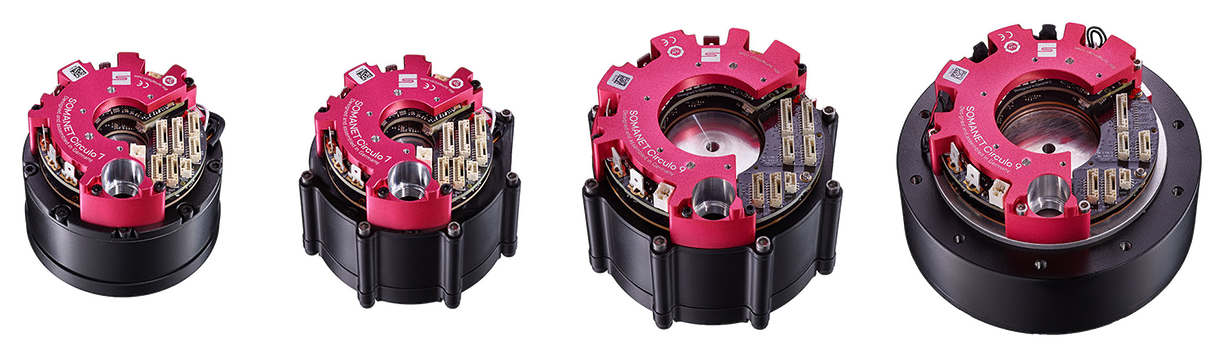
The ACTILINK-JD series combines a compact coaxial design with high torque density and a low-backlash gearbox. A single-stage planetary gearbox, a high-torque motor, and an integrated SOMANET™ Circulo drive ensure high dynamics, backdrivability, and reliability under mechanical load for humanoid robots, robotic dogs, and exoskeletons.
Single-stage planetary gearbox: coaxial design with low holding torque, quasi-direct drive with high dynamics and reverse drive capability.
Four sizes: JD08, JD09, JD10, and JD12, with maximum acceleration torque ranging from 17 to 102 Nm.
SOMANET™ Motion Drive: EtherCAT, high-performance motion control, high efficiency.
Functional Safety: STO and SBC as standard features; Safe Motion via FSoE as an option (SIL 3, PL e, Cat. 3).
4
SIZES: JD08, JD09, JD10, AND JD12
102 Nm
MAX. ACCELERATION TORQUE (JD12)
64.8 Nm/kg
TORQUE-RESISTANT TIP (JD10)
< 11 arcmin
GEAR RATIO (JD12)
Performance data at a 48 V supply voltage.
FEATURE
ACTILINK-JD08
ACTILINK-JD09 ▲
ACTILINK-JD10
ACTILINK-JD12
Product Variant
AJD-08-20-400
AJD-09-30-500
AJD-10-60-200
AJD-12-120-200
Supply Voltage
24 to 48 V, 60 V peak
24 to 48 V, 60 V peak
24 to 48 V, 60 V peak
24 to 48 V, 60 V peak
Peak torque density
33.3 Nm/kg
44.1 Nm/kg
64.8 Nm/kg
64.6 Nm/kg
Top Performance
397 W
696 W
624 W
1.036 W
Max. Acceleration Torque
17 Nm
30 Nm
68 Nm
102 Nm
Idle speed
400 rpm
470 rpm
210 rpm
200 rpm
Continuous torque
7 Nm
11 Nm
21 Nm
29 Nm
Rated speed
250 rpm
250 rpm
100 rpm
100 rpm
Outer diameter *
78.5 mm
88 mm
106 mm
120 mm
Length *
65.5 mm
70.29 mm
72.8 mm
72.8 mm
Weight *
510 g
680 g
1.050 g
1.580 g
Transmission
Single-stage planetary gearbox
Single-stage planetary gearbox
Single-stage planetary gearbox
Single-stage planetary gearbox
Translation
7.75 : 1
9 : 1
9 : 1
9 : 1
Integrated Drive
SOMANET Circulo 7
SOMANET Circulo 7
SOMANET Circulo 9
SOMANET Circulo 9
Motor Encoder
19-bit absolute, MT
19-bit absolute, MT
20-bit absolute, MT
20-bit absolute, MT
Output encoder
20-bit absolute at the output (Option D2)
20-bit absolute at the output (Option D2)
20-bit absolute at the output (Option D2)
20-bit absolute at the output (Option D2)
Communication
EtherCAT (DS402)
EtherCAT (DS402)
EtherCAT (DS402)
EtherCAT (DS402)
Security Features
STO-SBC / Safe Motion (FSoE)
STO-SBC / Safe Motion (FSoE)
STO-SBC / Safe Motion (FSoE)
STO-SBC / Safe Motion (FSoE)
▲ ACTILINK-JD09 is a prototype product. * The outer diameter, length, and weight apply to the ECS1SS model with a single encoder. ECD2 models with dual encoders also include the output encoder; see the respective variant for details.
AJD-08-20-400
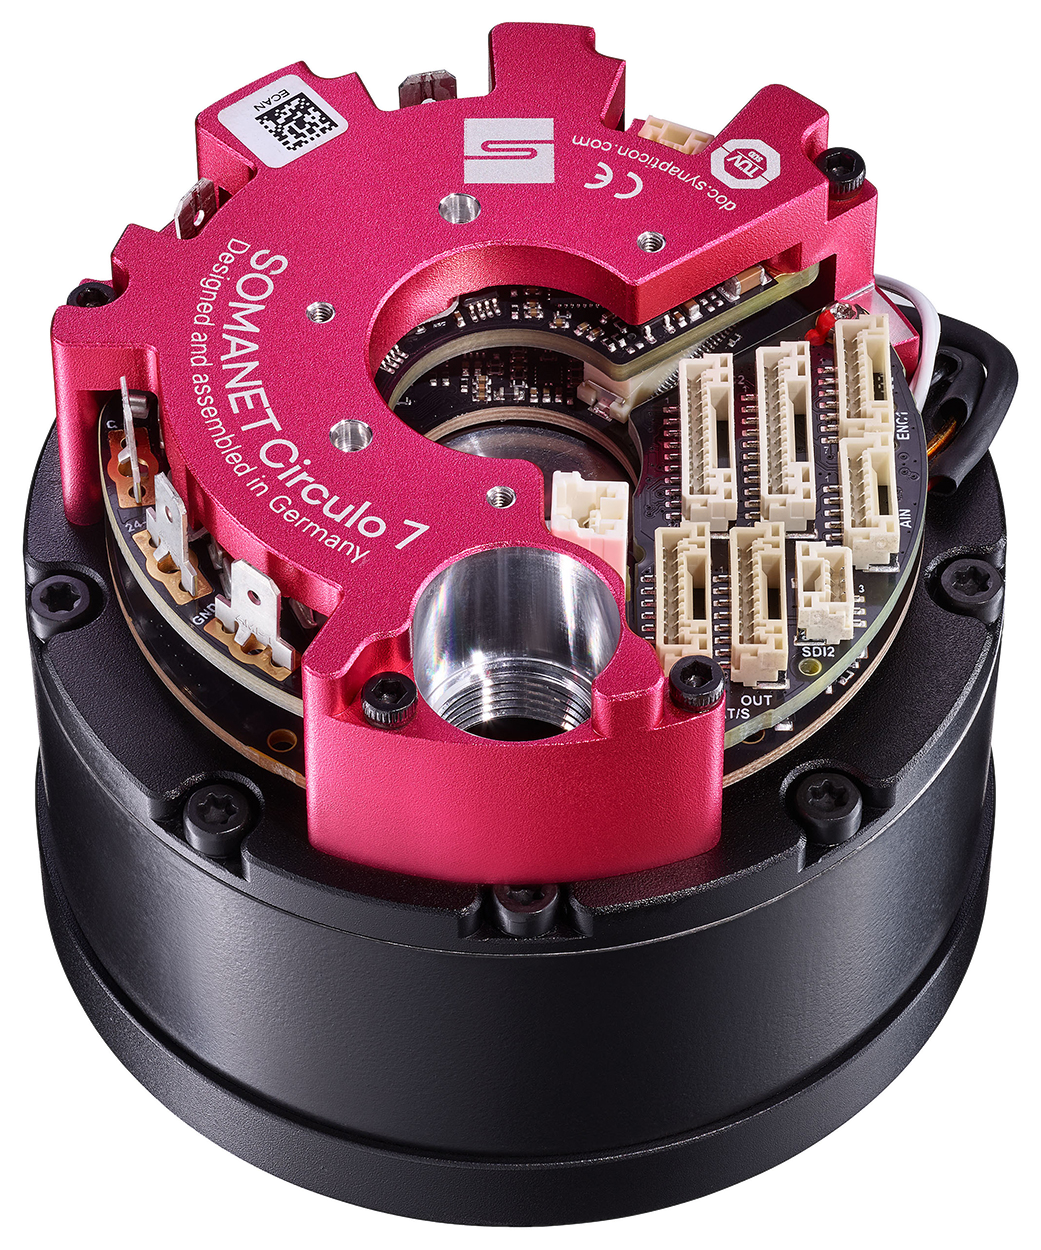
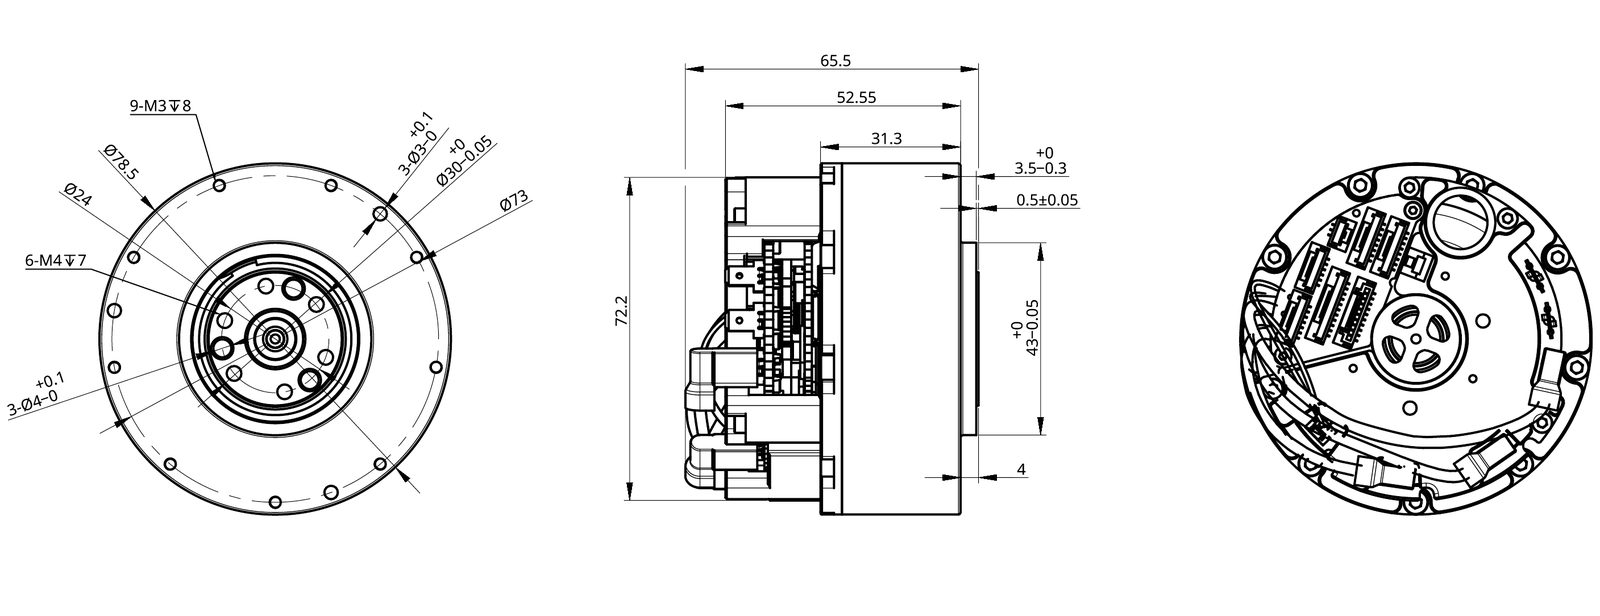
Dimensional Drawing ECS1: An integrated encoder (motor). All dimensions are in mm.
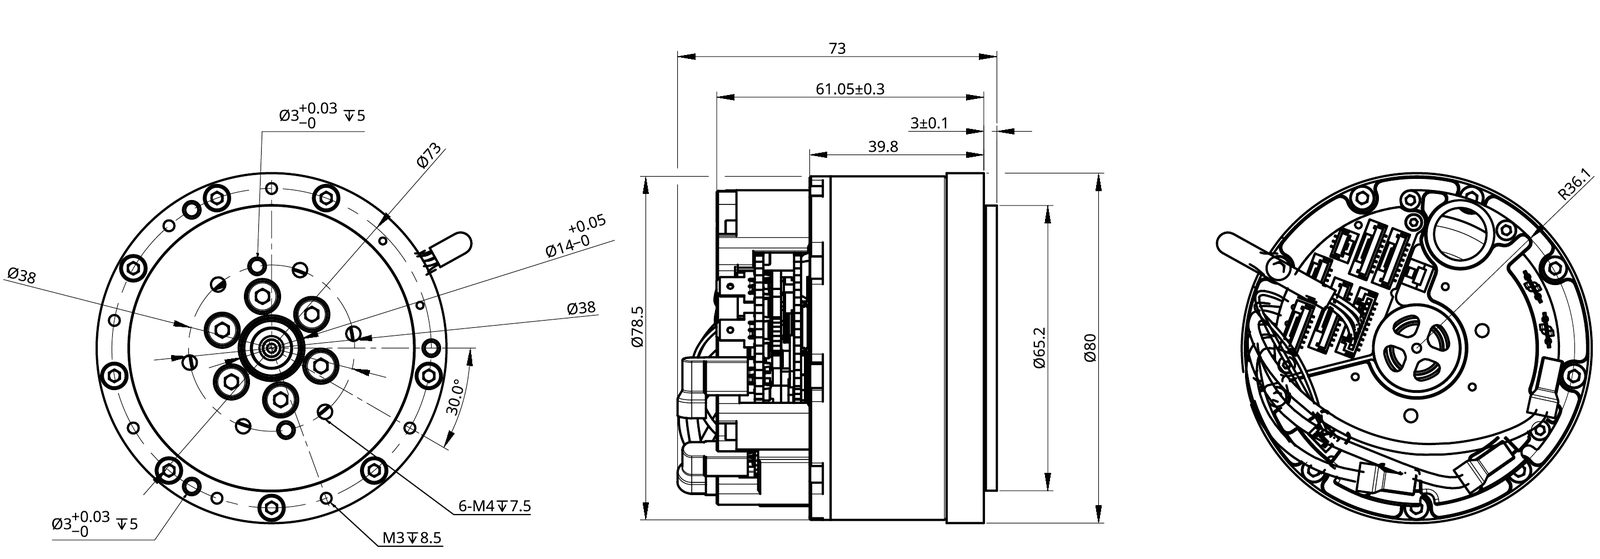
Dimensional Drawing ECD2: Dual Encoder (Motor and Output). All dimensions are in mm.
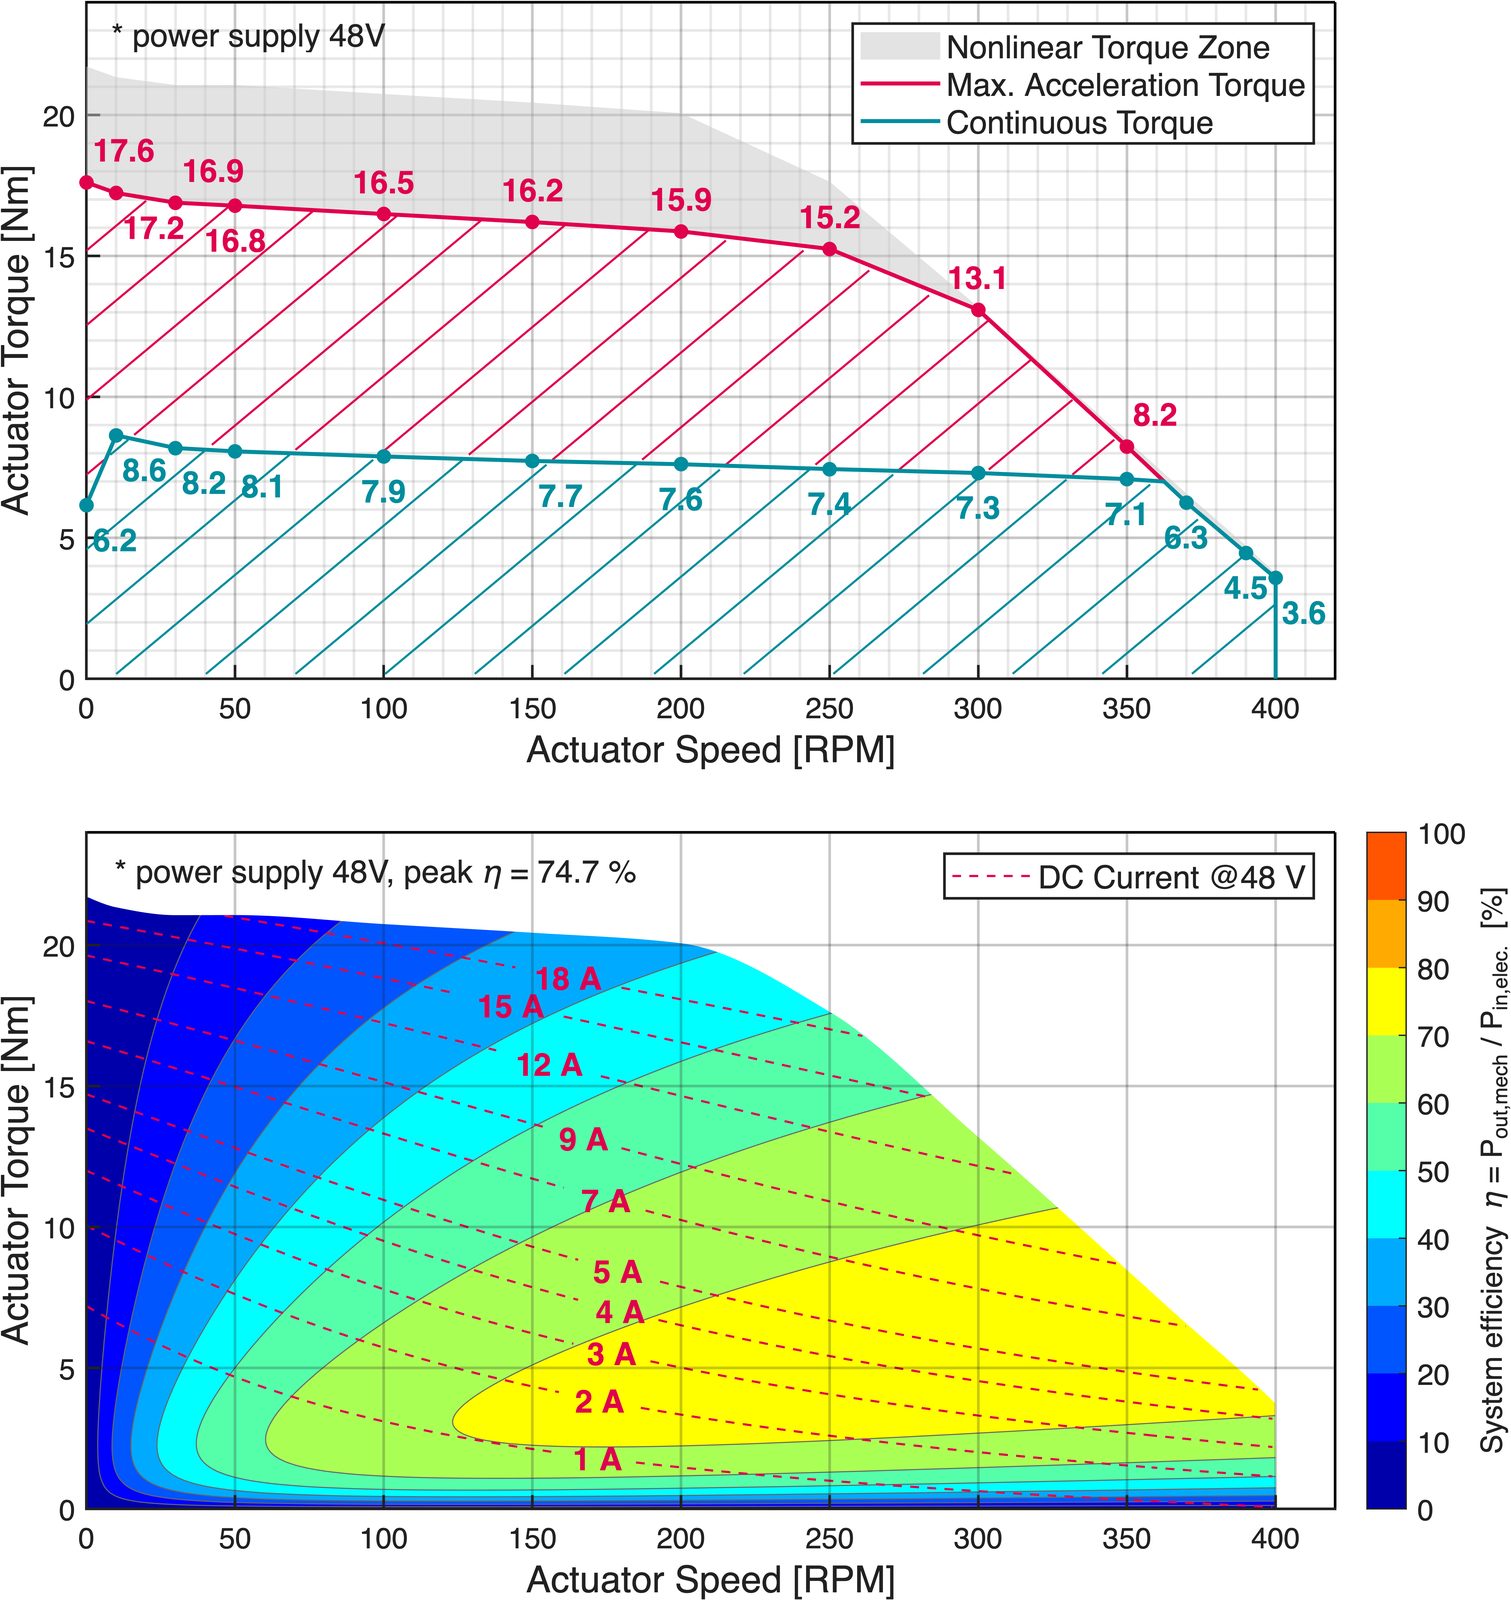
Torque-speed characteristics at 48 V (continuous torque at 25 °C ambient temperature, maximum acceleration torque, nonlinear range) and system efficiency with DC current.
POWER AT 48 V
Continuous torque
7 Nm
Max. Acceleration Torque
17 Nm
Top Performance
397 W
Rated speed
250 rpm
Idle speed
400 rpm
Peak torque density
33.3 Nm/kg
EMERGENCY STOP MODE
Emergency Stop Moment
30 Nm
Emergency Stop Delay
6,000 rad/s²
MECHANICS
Weight †
510 g
Outer diameter †
78.5 mm
Length †
65.5 mm
Inertia (based on the transmission)
0.0042 kg·m²
Transmission
Single-stage planetary gearbox
Translation
7.75 : 1
Gearplay
< 22 arcmin
PERMISSIBLE LOAD ‡
Tipping Moment (S1 / D2)
K · 3.4 / 3.2 Nm
Radial load (S1 / D2)
K · 167.4 / 161.8 N
Axial load
K · 107.2 N
K for static load
2,21
POWER TRAIN AND ELECTRONICS
Motor
14 pairs of poles (28 poles)
Torque constant
156.4 mNm/arm
Phase resistance
270 mΩ
Phase inductance
167 µH at 1 kHz
Integrated Drive
SOMANET Circulo 7 (CR7-48-24)
Supply Voltage
24 to 48 V, 60 V peak
FEEDBACK AND SECURITY
Motor Encoder
19-bit absolute, MT (battery)
Output Encoder (Optional)
20-bit absolute at the gearbox output
Communication
EtherCAT (DS402)
Security Features
STO-SBC / Safe Motion (FSoE)
STANDARD CONFIGURATIONS
AJD-08…ECS1SS
Motor Encoder, STO-SBC
AJD-08…ECD2SS
+ Output encoder, STO-SBC
AJD-08…ECD2SM
+ Output encoder, Safe Motion
SURROUNDINGS
Operating temperature
0 to 50 °C (ambient air)
Storage Temperature
-30 to 70 °C
† ECS1SS model (Ø 78.5 mm). ECD2 models have a diameter of 80 mm: 620 g / 73 mm (D2SS), 640 g / 73 mm (D2SM). ‡ The permissible load uses the constant K: K = 1 at rated speed and a service life of 10,000 h; K = (10,000 · rated speed / t / v)^1/3 for speed v in rpm and service life t in hours.
AJD-09-30-500
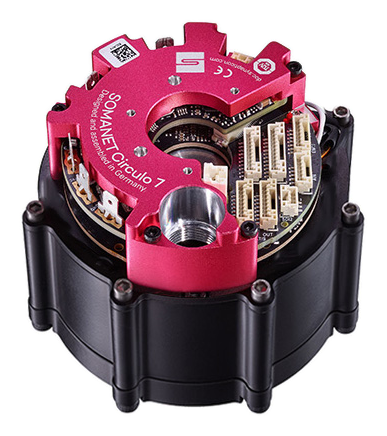

Dimensional Drawing ECS1: An integrated encoder (motor). All dimensions are in mm.
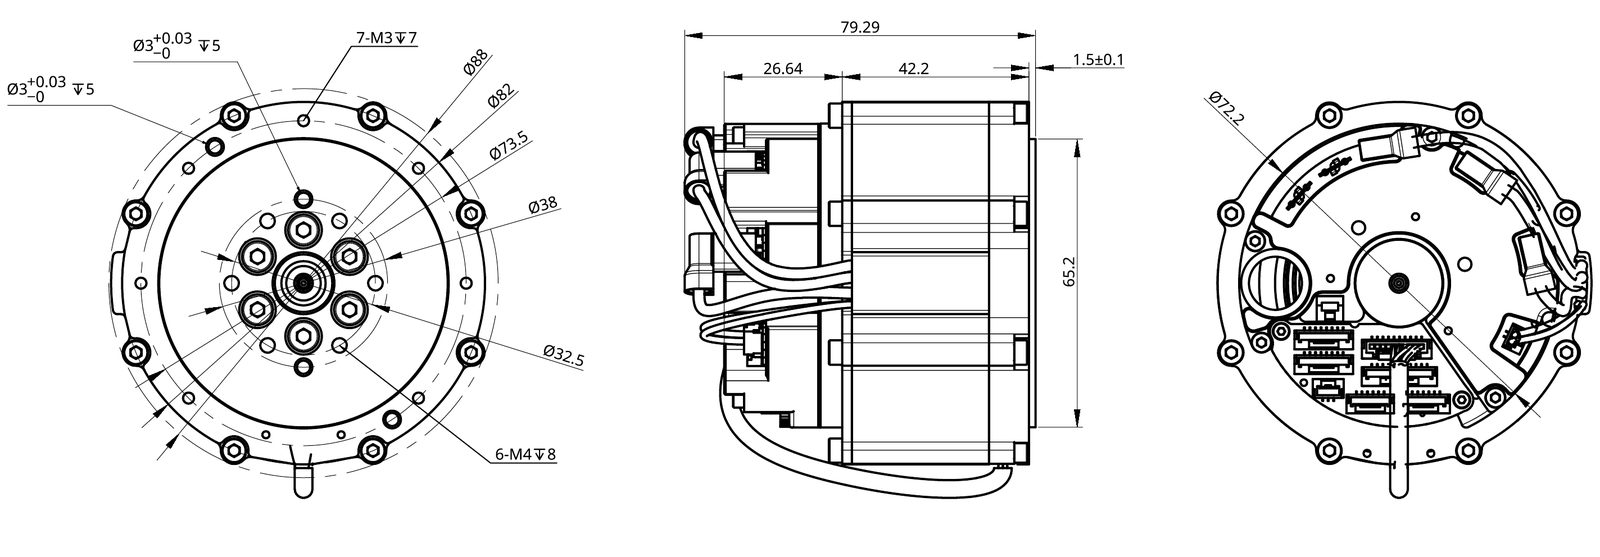
Dimensional Drawing ECD2: Dual Encoder (Motor and Output). All dimensions are in mm.
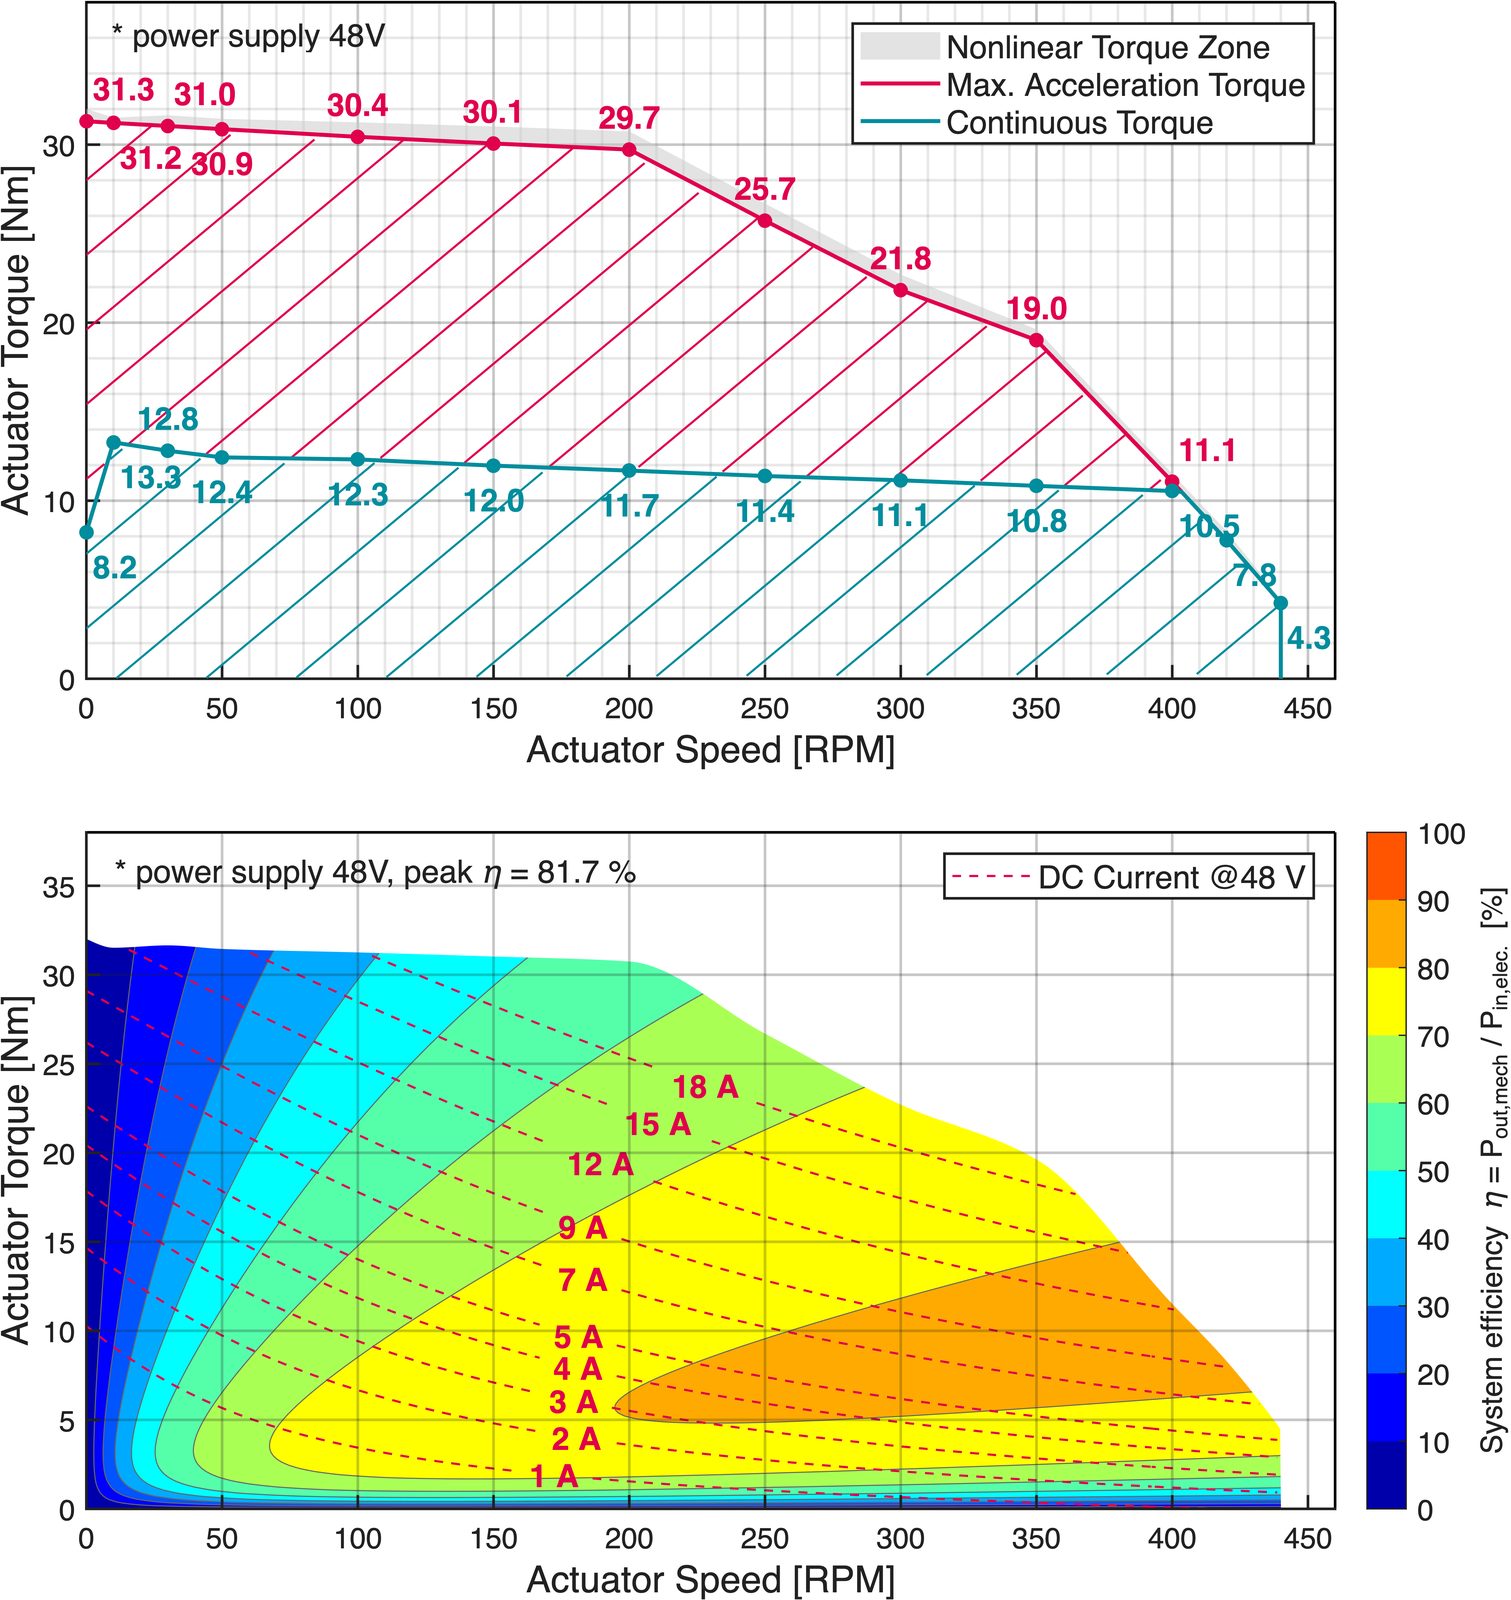
Torque-speed characteristics at 48 V (continuous torque at 25 °C ambient temperature, maximum acceleration torque, nonlinear range) and system efficiency with DC current.
POWER AT 48 V
Continuous torque
11 Nm
Max. Acceleration Torque
30 Nm
Top Performance
696 W
Rated speed
250 rpm
Idle speed
470 rpm
Peak torque density
44.1 Nm/kg
EMERGENCY STOP MODE
Emergency Stop Moment
follows
Emergency Stop Delay
follows
MECHANICS
Weight †
680 g
Outer diameter
88 mm
Length †
70.29 mm
Inertia (based on the transmission)
0.0086 kg·m²
Transmission
Single-stage planetary gearbox
Translation
9 : 1
Gearplay
< 15 arcmin
PERMISSIBLE LOAD ‡
Tipping moment
K · 12.5 Nm
Radial load (S1 / D2)
K · 595.9 / 417.2 N
Axial load
K · 446.9 N
K for static load
1,78
POWER TRAIN AND ELECTRONICS
Motor
14 pairs of poles (28 poles)
Torque constant
122.2 mNm/arm
Phase resistance
110 mΩ
Phase inductance
72 µH at 1 kHz
Integrated Drive
SOMANET Circulo 7 (CR7-48-24)
Supply Voltage
24 to 48 V, 60 V peak
FEEDBACK AND SECURITY
Motor Encoder
19-bit absolute, MT (battery)
Output Encoder (Optional)
20-bit absolute at the gearbox output
Communication
EtherCAT (DS402)
Security Features
STO-SBC / Safe Motion (FSoE)
STANDARD CONFIGURATIONS
AJD-09…ECS1SS
Motor Encoder, STO-SBC
AJD-09…ECD2SS
+ Output encoder, STO-SBC
AJD-09…ECD2SM
+ Output encoder, Safe Motion
SURROUNDINGS
Operating temperature
0 to 50 °C (ambient air)
Storage Temperature
-30 to 70 °C
† Model ECS1SS. ECD2SS: 800 g / 79.29 mm, ECD2SM: 820 g / 79.29 mm. ACTILINK-JD09 is a prototype; specific values will be provided later. ‡ The permissible load uses the constant K: K = 1 at rated speed and a service life of 10,000 h; K = (10,000 · rated speed / t / v)^1/3 for speed v in rpm and service life t in hours.
AJD-10-60-200
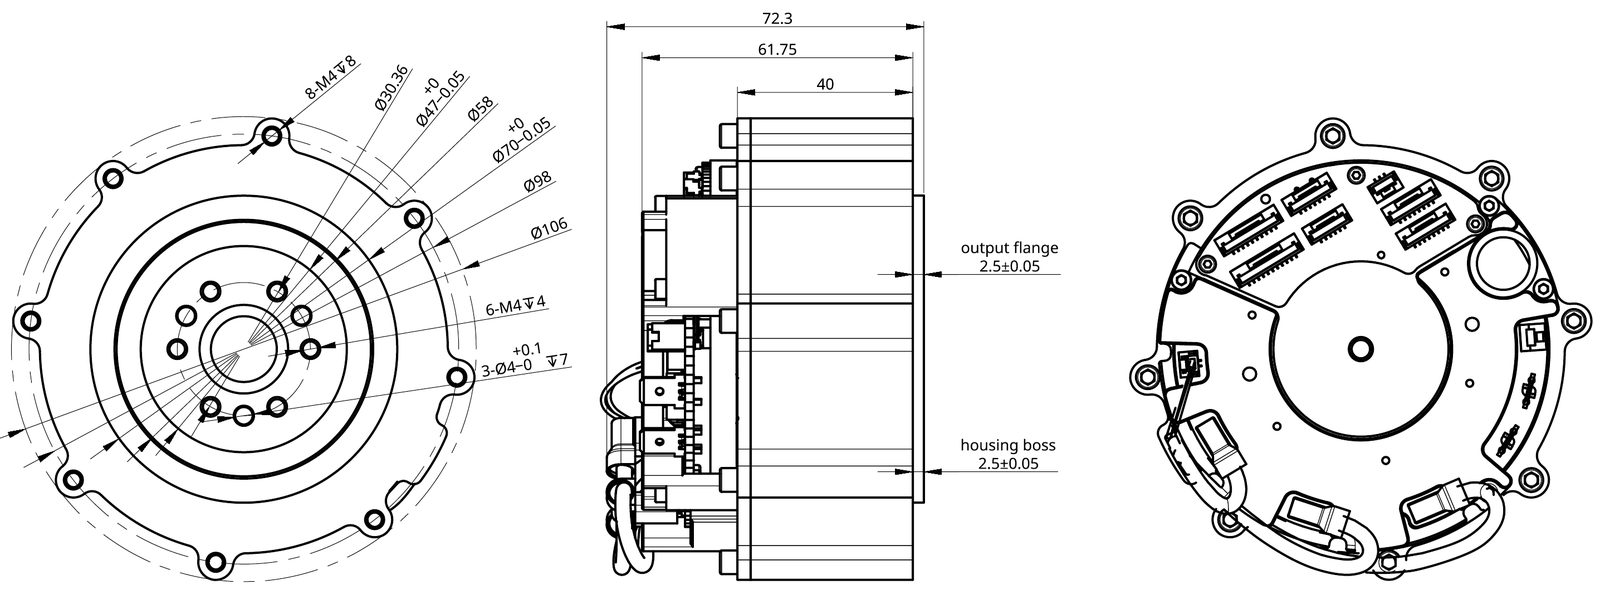
Dimensional Drawing ECS1: An integrated encoder (motor). All dimensions are in mm.
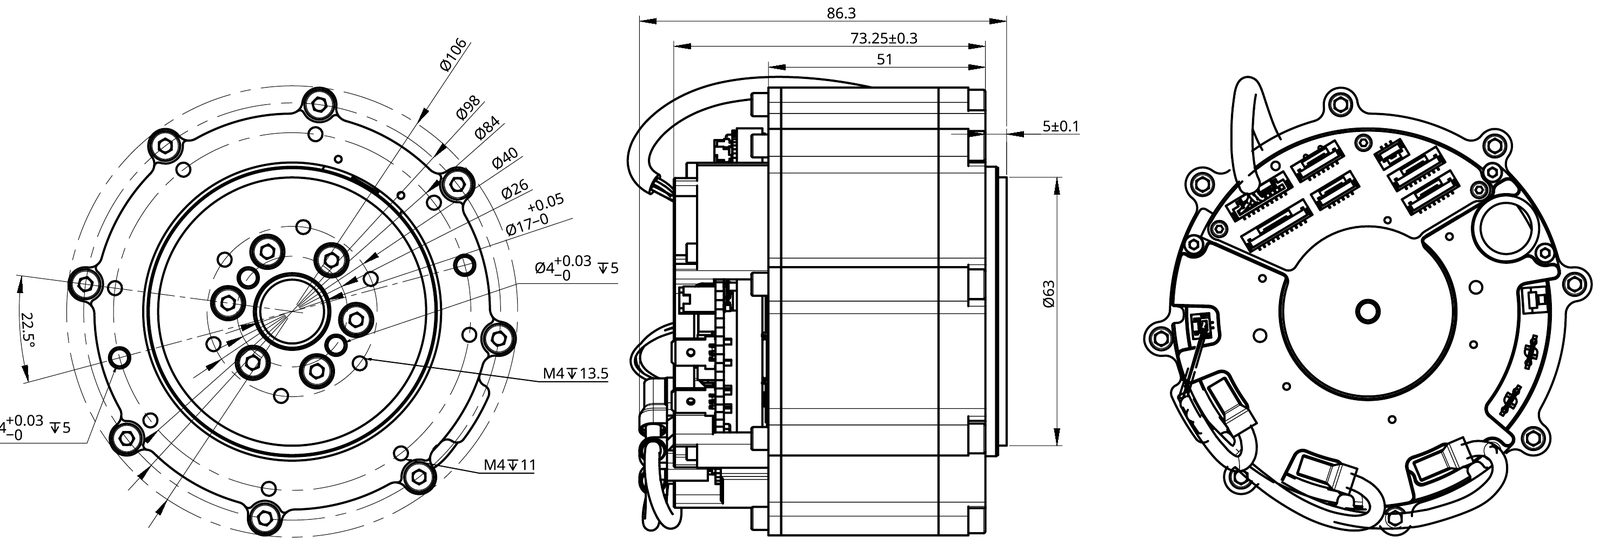
Dimensional Drawing ECD2: Dual Encoder (Motor and Output). All dimensions are in mm.
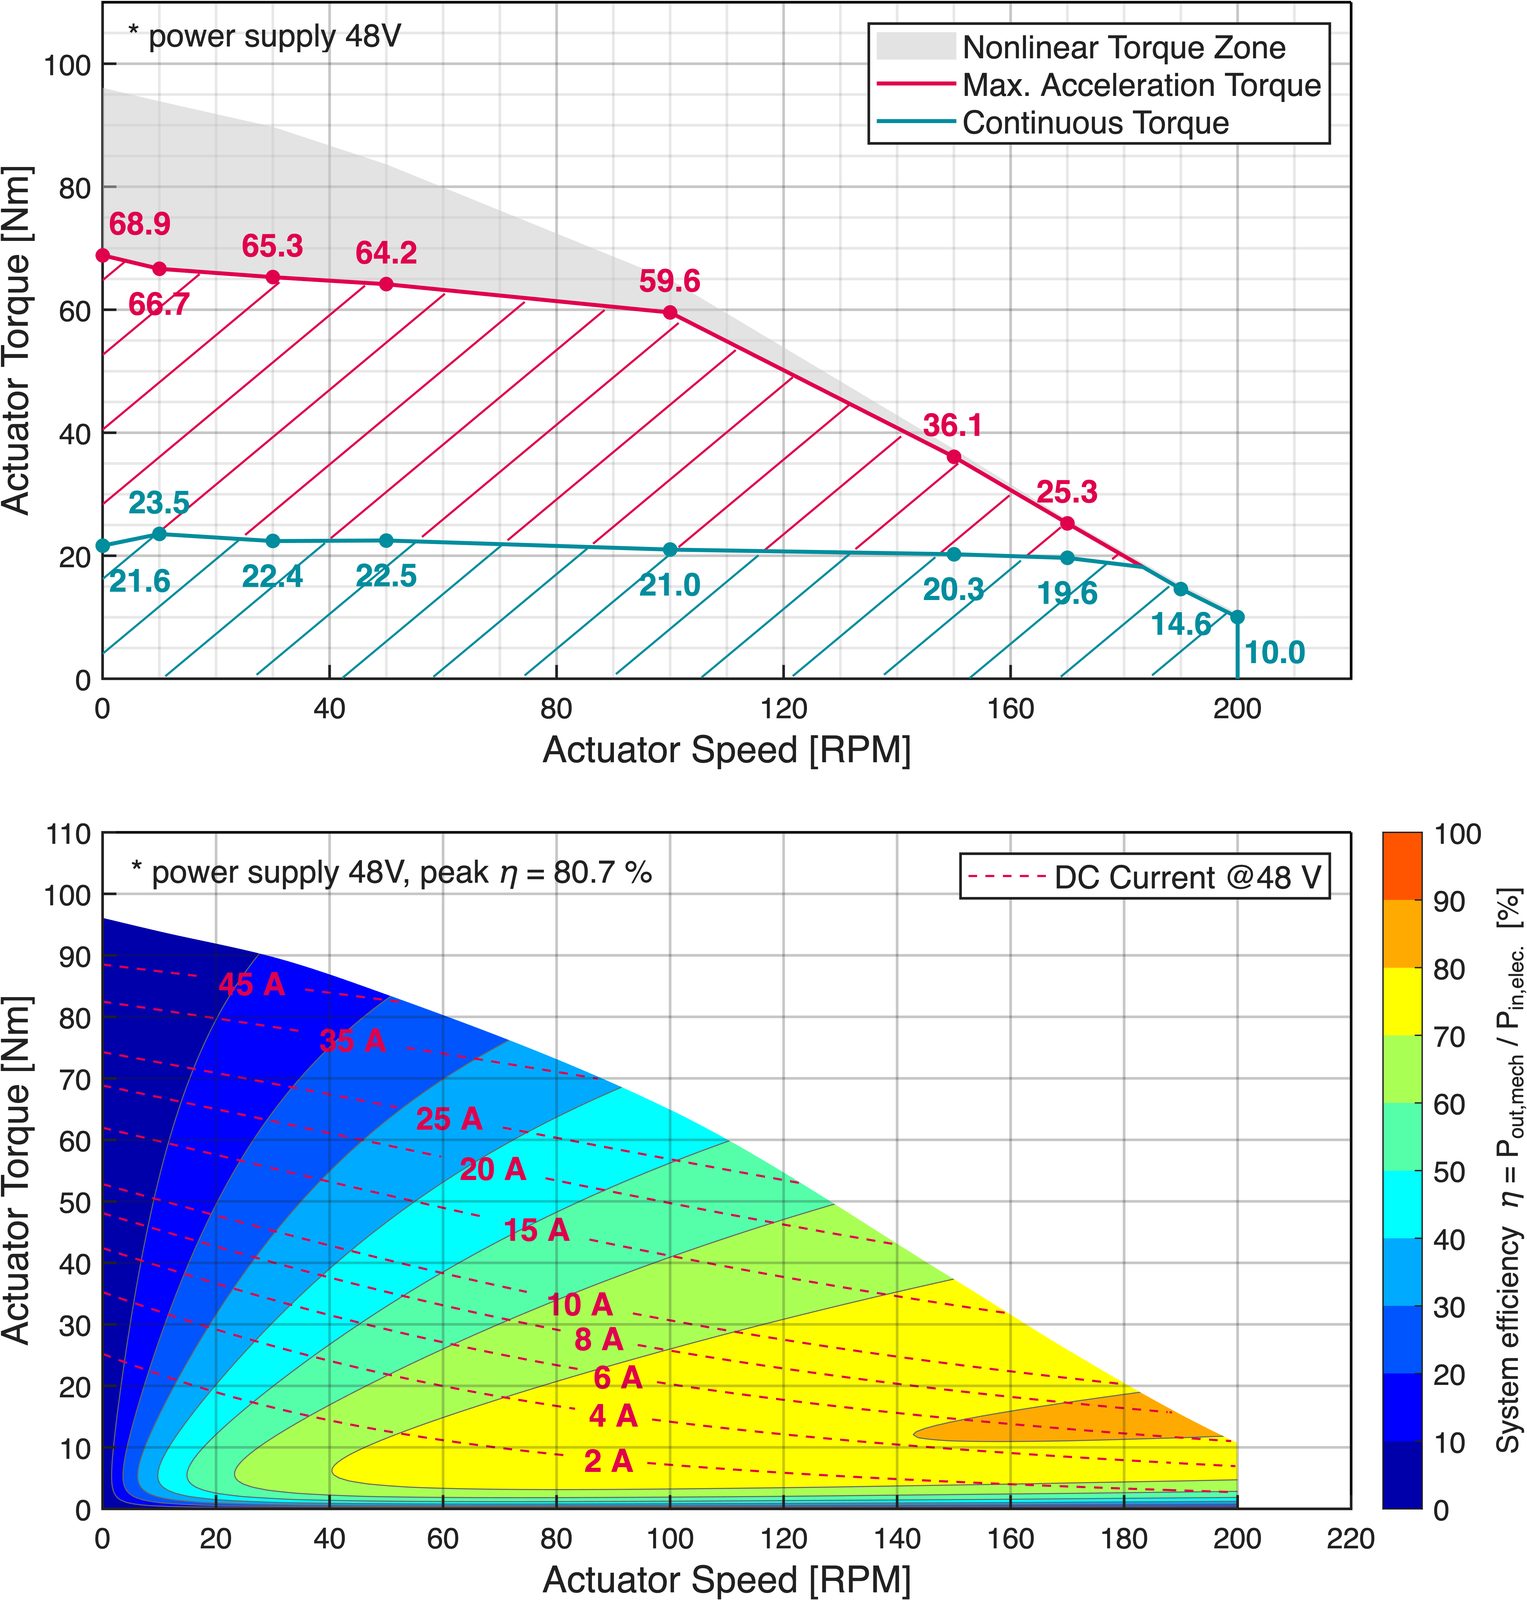
Torque-speed characteristics at 48 V (continuous torque at 25 °C ambient temperature, maximum acceleration torque, nonlinear range) and system efficiency with DC current.
POWER AT 48 V
Continuous torque
21 Nm
Max. Acceleration Torque
68 Nm
Top Performance
624 W
Rated speed
100 rpm
Idle speed
210 rpm
Peak torque density
64.8 Nm/kg
EMERGENCY STOP MODE
Emergency Stop Moment
105 Nm
Emergency Stop Delay
4,200 rad/s²
MECHANICS
Weight †
1.050 g
Outer diameter
106 mm
Length †
72.8 mm
Inertia (based on the transmission)
0.02 kg·m²
Transmission
Single-stage planetary gearbox
Translation
9 : 1
Gearplay
< 13 arcmin
PERMISSIBLE LOAD ‡
Tipping moment
K · 24.5 Nm
Radial load (S1 / D2)
K · 1,021.7 / 653.9 N
Axial load
K · 766.3 N
K for static load
1,92
POWER TRAIN AND ELECTRONICS
Motor
20 pairs of poles (40 poles)
Torque constant
241.7 mNm/arm
Phase resistance
195 mΩ
Phase inductance
110 µH at 1 kHz
Integrated Drive
SOMANET Circulo 9 (CR9-48-60)
Supply Voltage
24 to 48 V, 60 V peak
FEEDBACK AND SECURITY
Motor Encoder
20-bit absolute, MT (battery)
Output Encoder (Optional)
20-bit absolute at the gearbox output
Communication
EtherCAT (DS402)
Security Features
STO-SBC / Safe Motion (FSoE)
STANDARD CONFIGURATIONS
AJD-10…ECS1SS
Motor Encoder, STO-SBC
AJD-10…ECD2SS
+ Output encoder, STO-SBC
AJD-10…ECD2SM
+ Output encoder, Safe Motion
SURROUNDINGS
Operating temperature
0 to 50 °C (ambient air)
Storage Temperature
-30 to 70 °C
† Model ECS1SS. ECD2SS: 1,230 g / 86.3 mm, ECD2SM: 1,255 g / 86.3 mm. ‡ The permissible load uses the constant K: K = 1 at rated speed and a service life of 10,000 h; K = (10,000 · rated speed / t / v)^1/3 for speed v in rpm and service life t in hours.
AJD-12-120-200
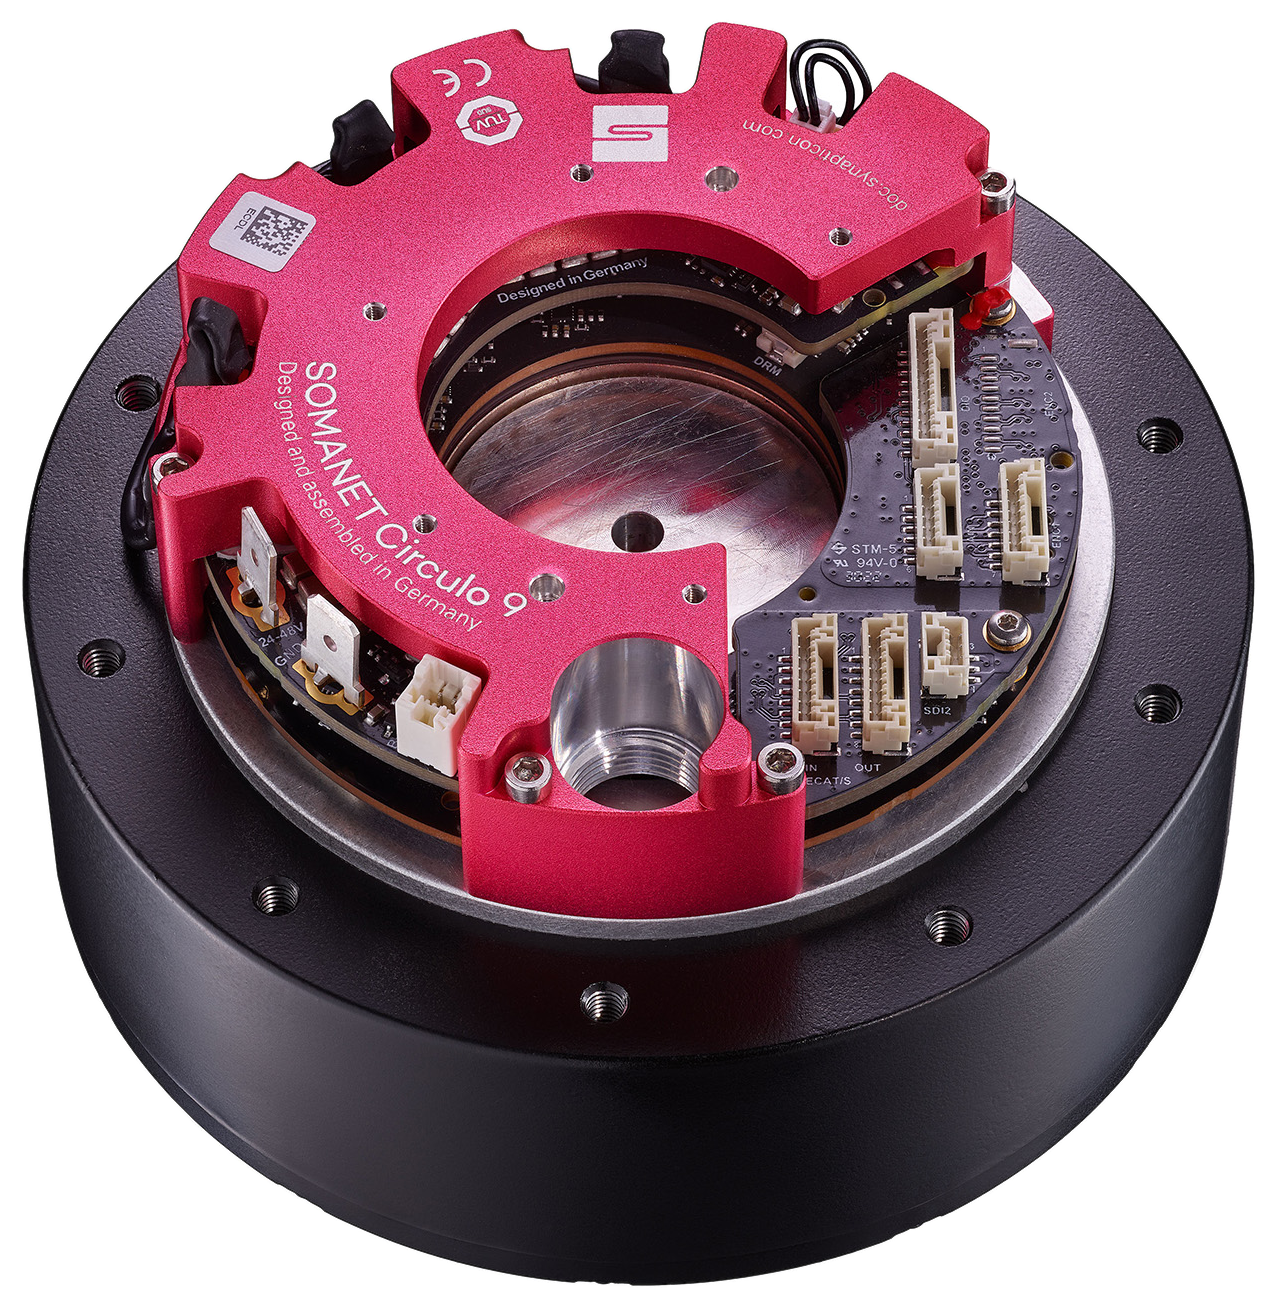
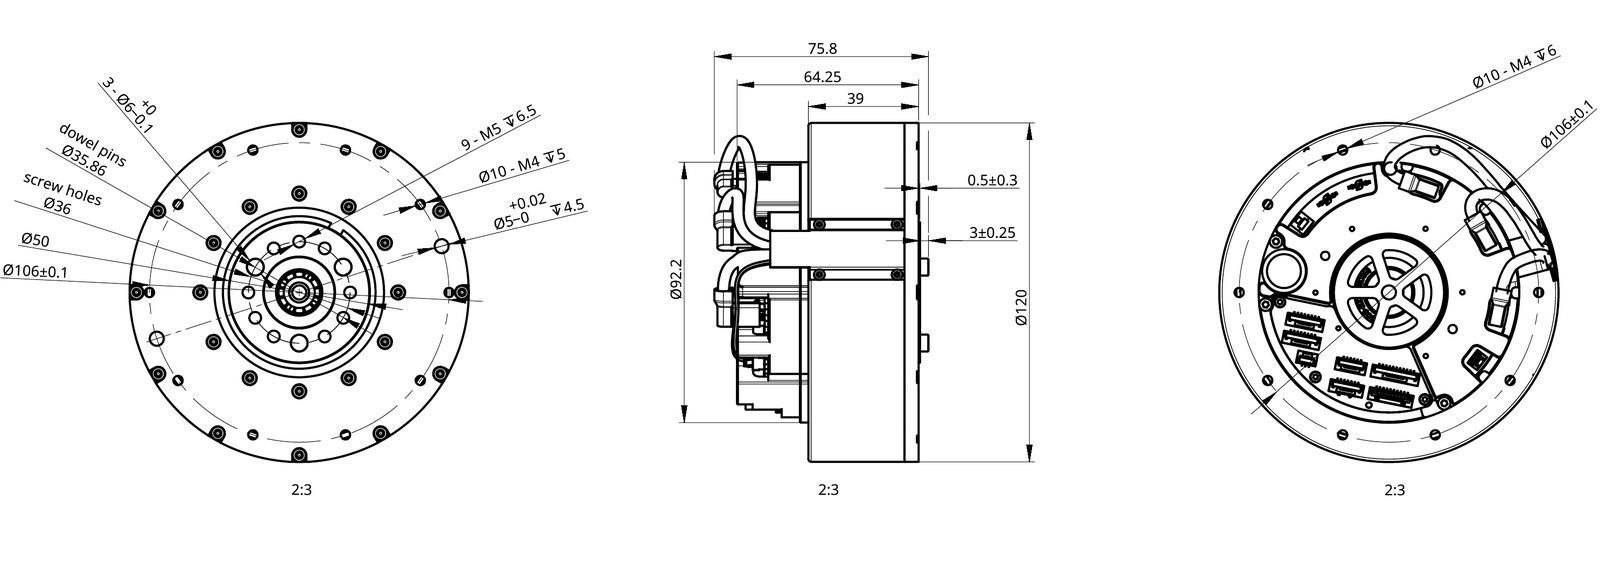
Dimensional Drawing ECS1: An integrated encoder (motor). All dimensions are in mm.
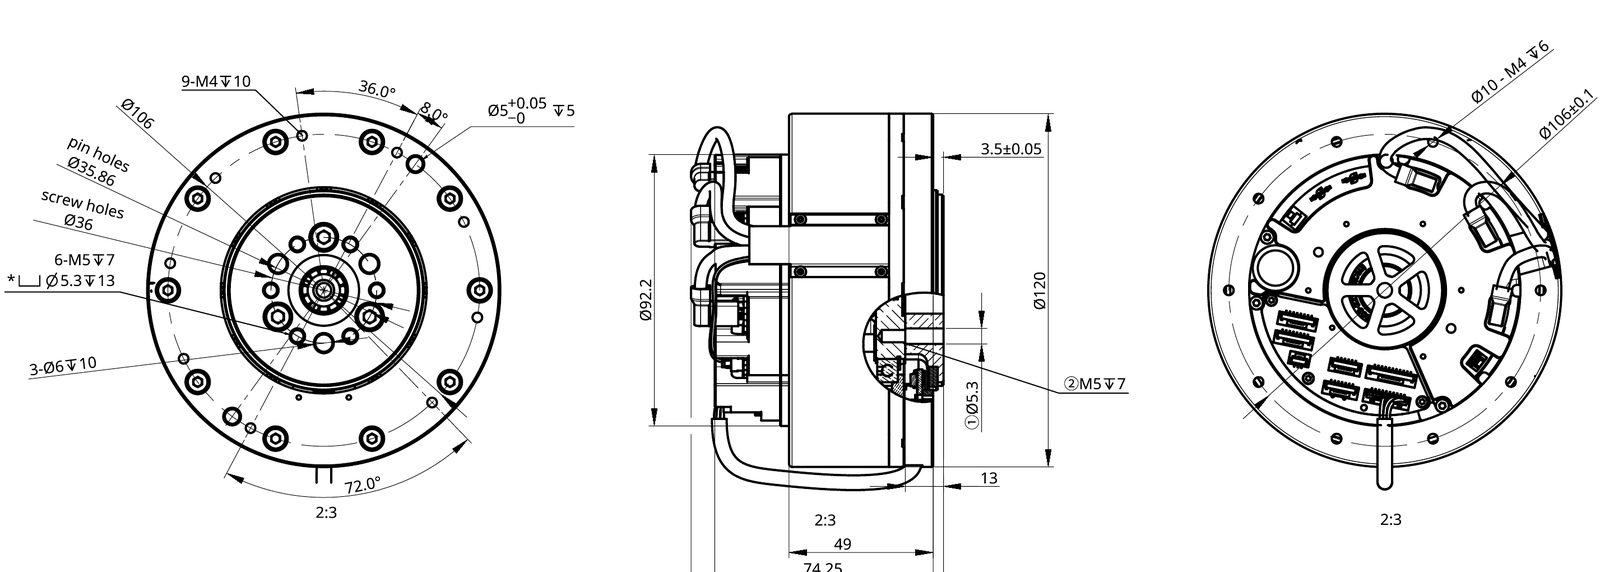
Dimensional Drawing ECD2: Dual Encoder (Motor and Output). All dimensions are in mm.
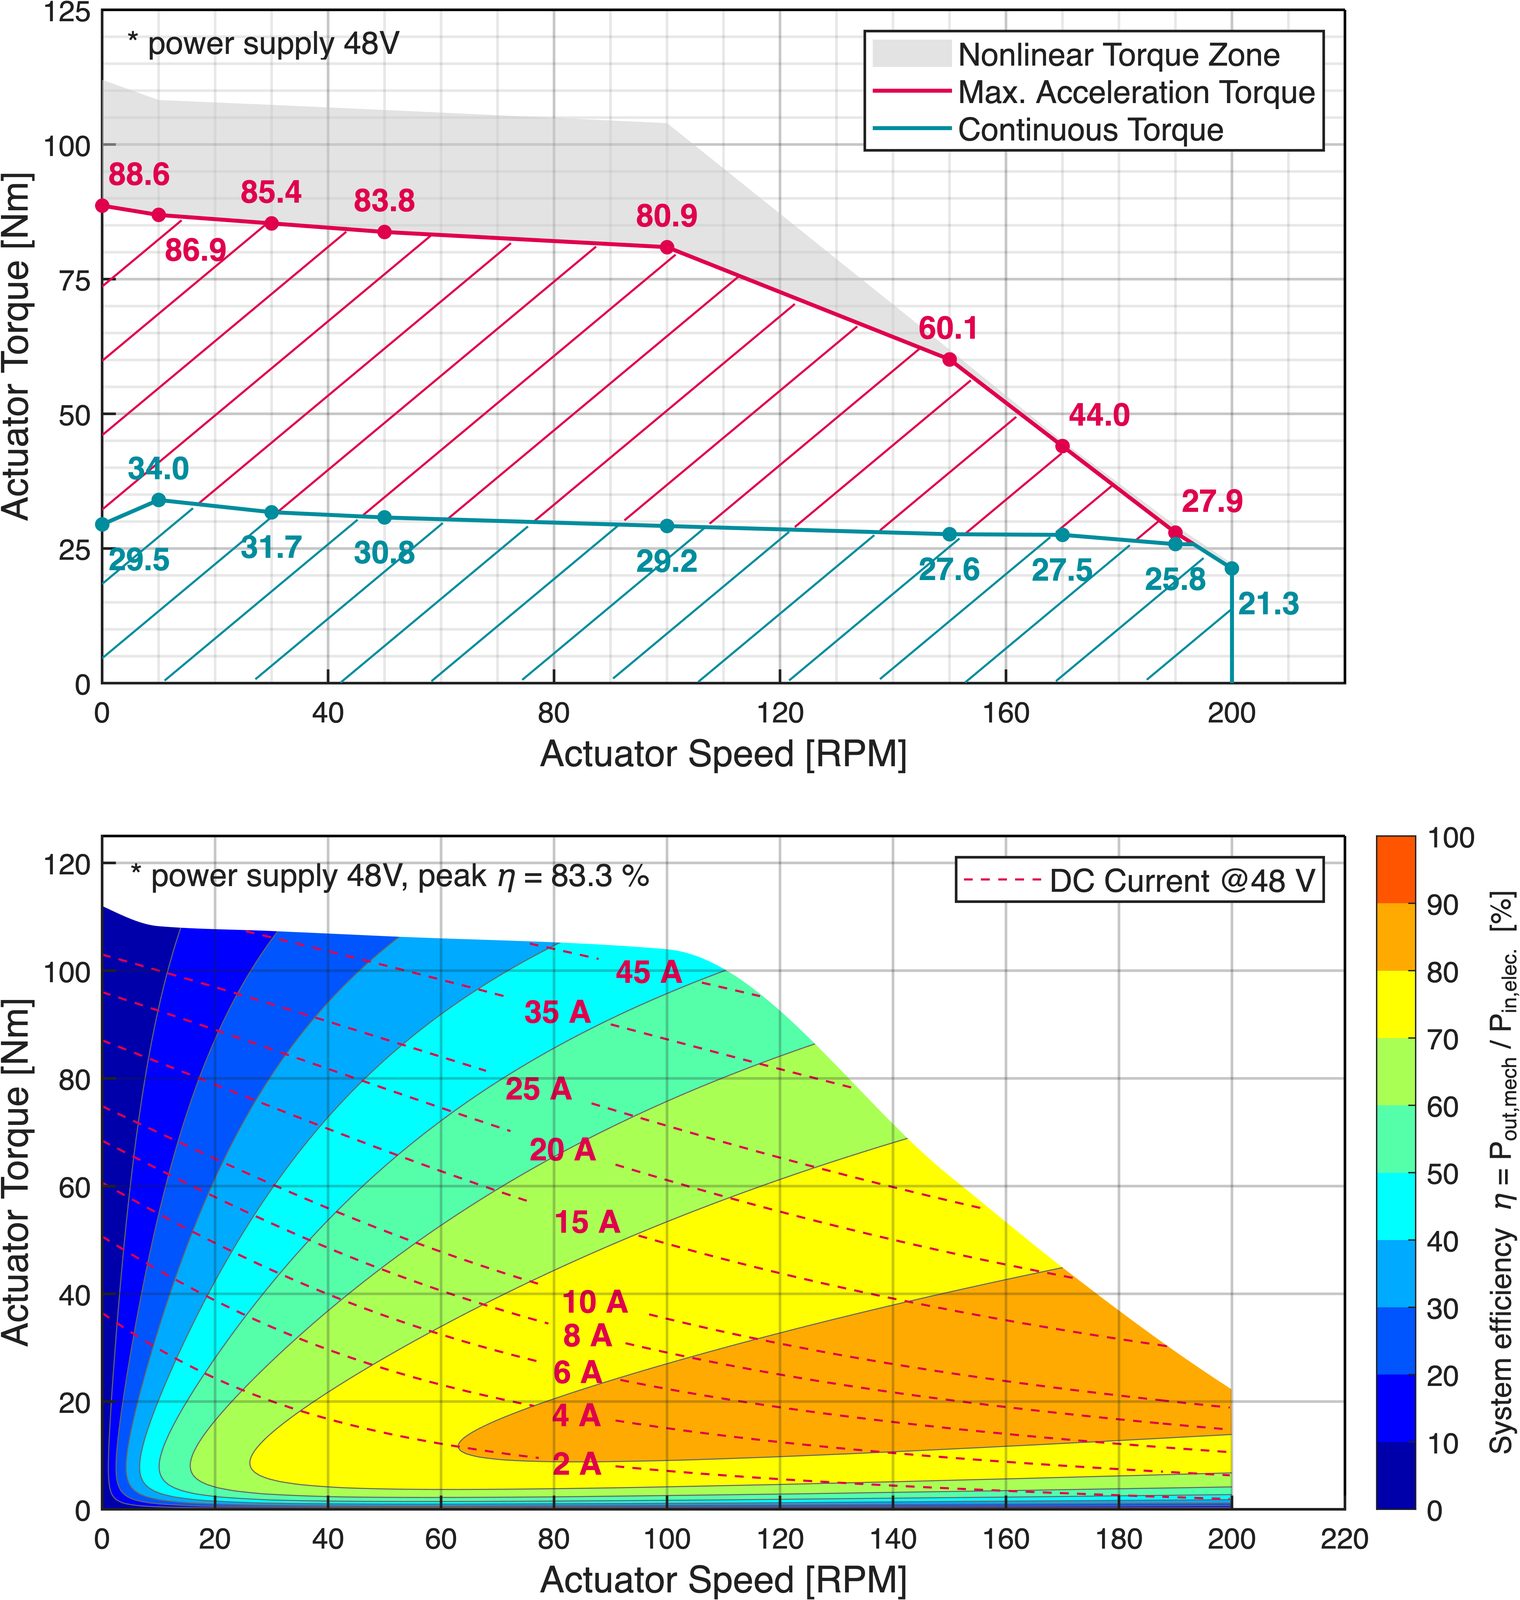
Torque-speed characteristics at 48 V (continuous torque at 25 °C ambient temperature, maximum acceleration torque, nonlinear range) and system efficiency with DC current.
POWER AT 48 V
Continuous torque
29 Nm
Max. Acceleration Torque
102 Nm
Top Performance
1.036 W
Rated speed
100 rpm
Idle speed
200 rpm
Peak torque density
64.6 Nm/kg
EMERGENCY STOP MODE
Emergency Stop Moment
210 Nm
Emergency Stop Delay
4,200 rad/s²
MECHANICS
Weight †
1.580 g
Outer diameter
120 mm
Length †
72.8 mm
Inertia (based on the transmission)
0.04 kg·m²
Transmission
Single-stage planetary gearbox
Translation
9 : 1
Gearplay
< 11 arcmin
PERMISSIBLE LOAD ‡
Tipping moment
K · 30.6 Nm
Radial load (S1 / D2)
K · 1,331.0 / 850.4 N
Axial load
K · 900.4 N
K for static load
1,72
POWER TRAIN AND ELECTRONICS
Motor
21 pairs of poles (42 poles)
Torque constant
233.9 mNm/arm
Phase resistance
85 mΩ
Phase inductance
90 µH at 1 kHz
Integrated Drive
SOMANET Circulo 9 (CR9-48-60)
Supply Voltage
24 to 48 V, 60 V peak
FEEDBACK AND SECURITY
Motor Encoder
20-bit absolute, MT (battery)
Output Encoder (Optional)
20-bit absolute at the gearbox output
Communication
EtherCAT (DS402)
Security Features
STO-SBC / Safe Motion (FSoE)
STANDARD CONFIGURATIONS
AJD-12…ECS1SS
Motor Encoder, STO-SBC
AJD-12…ECD2SS
+ Output encoder, STO-SBC
AJD-12…ECD2SM
+ Output encoder, Safe Motion
SURROUNDINGS
Operating temperature
0 to 50 °C (ambient air)
Storage Temperature
-30 to 70 °C
† Model ECS1SS. ECD2SS: 1,845 g / 85.5 mm, ECD2SM: 1,870 g / 85.5 mm. ‡ The permissible load uses the constant K: K = 1 at rated speed and a service life of 10,000 h; K = (10,000 · rated speed / t / v)^1/3 for speed v in rpm and service life t in hours.
The manufacturer's part number (MPN) uniquely identifies each model. Example: AJD-08-20-400-ECD2SMS-00
PRODUCT FAMILY
AJD
Actilink Joint Dynamic
OUTER DIAMETER, TORQUE, AND SPEED CLASS
08-20-400
08-20-400: Ø 78.5 mm, approx. 20 Nm, 7.75:1 · 09-30-500: Ø 88 mm, approx. 30 Nm, 9:1 · 10-60-200: Ø 106 mm, approx. 60 Nm, 9:1 · 12-120-200: Ø 120 mm, approx. 120 Nm, 9:1 · 10-40-500: Ø 106 mm, approx. 40 Nm, 9:1
FIELD BUS
EC
EC: EtherCAT
FEEDBACK ENCODER
D2
S1: one internal encoder (motor) · D2: dual encoder, internal on the motor, external on the output shaft · D3: other combinations
SAFETY
SM
SS: STO / SBC via IO · SM: Safe Motion (SIL 3, PL e, Cat. 3)
BRAKE
S
N: no brake · S: spring-actuated friction brake · P: permanent magnet friction brake · M: Synapticon Microcoil (retractable magnet bolt)
VERSION
00
00: Standard Version
CUSTOMER-SPECIFIC
XXXX
blank: Default
Standard configurations are listed for each model. Custom configurations, delivery times, and minimum order quantities are available upon request.
Beyond the mechanical components, Synapticon provides drives, control systems, and sensors, all the way through to the control and safety of the entire system: concepts, designs, feasibility studies, and integration across the entire robot system.
Brake: Friction brake or Synapticon Microcoil
Mechanical Design and Interfaces Suitable for Integration
Engine and Transmission Selection (Gear Ratio, Torque, and RPM Range)
Additional Sensors: Torque Measurement, IMU
Design of Bearing and Load-Bearing Structures
Balancing Thermal Performance, Emergency Stop, and Service Life
Upon request; NRE costs may apply. Subject to technical changes.
